|
I am currently pursuing a PhD in Robotics at the Department of Computer Science, The University of Hong Kong (HKU). In parallel, I co-founded Omni-X Robotics, a startup building teleoperation and data collection systems for robot learning, where I serve as CEO. Prior to this, I completed an integrated MEng (with Bachelor's degree incorporated) in Electrical and Electronic Engineering at Imperial College London. In addition to my academic training, I have extensive industry experience. At HKU, I collaborate with TransGP through the InnoHK initiative. Before starting my doctoral studies, I worked at Huawei on optical network optimization and planning, and earlier completed an internship at Ocado Technology in the UK. Email / Google Scholar / Github / LinkedIn |

|
|
|
|
Co-founder & CEO Omni-X Robotics builds robot teleoperation master arms (OmniLink) and a data platform (OmniPipe), providing a one-stop toolchain from hardware to software for robot skill data collection and model training. |
|
I hold a broad interest in a variety of topics in robotics. In particular, I work on robotics task understanding/planning. My ultimate goal is to develop robots that can learn, reason, interact and evolve in real-world settings. Besides my profession, I have a great fondness about history and philosophy. Some papers are highlighted. |
|
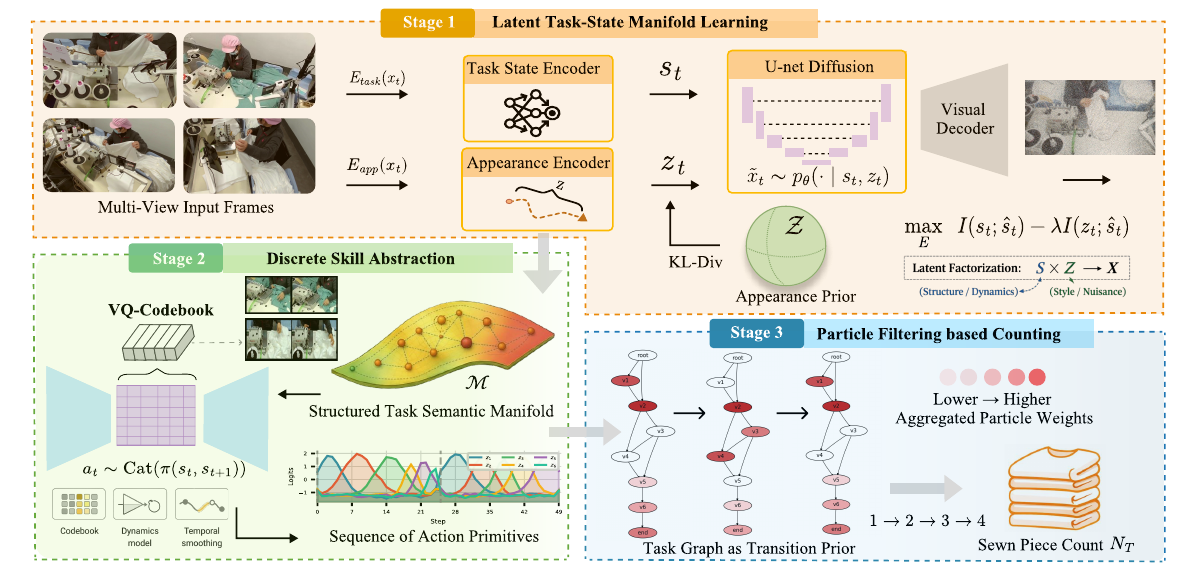
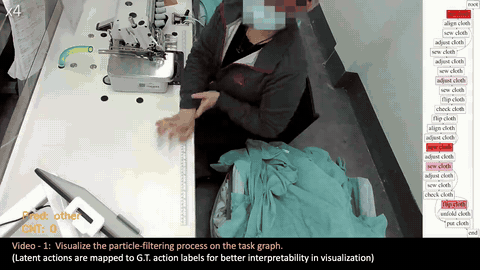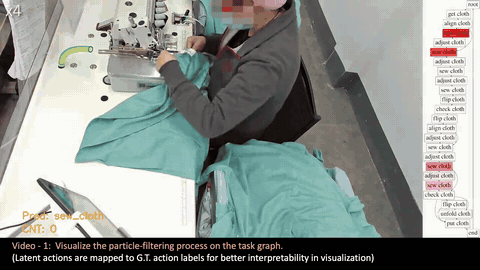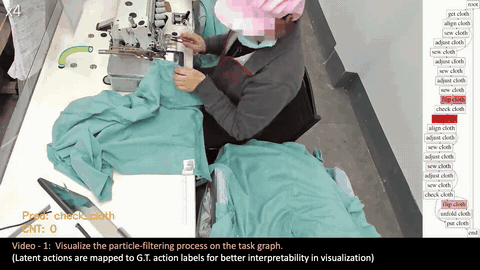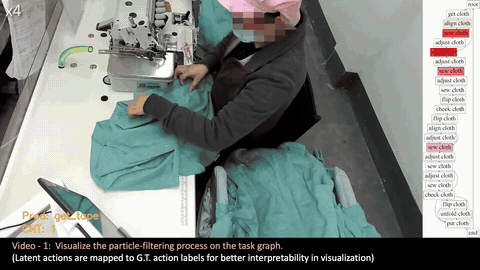
Zhongxuan Li, Yilin Wen, Lei Yang, Jia Pan†, Peng Zhou† IEEE Transactions on Industrial Informatics (TII), 2026 paper We propose a self-supervised framework for video-based sewn piece counting that learns task representations and dynamics directly from unsegmented demonstrations, without manual action annotation. The framework learns a task-state manifold via self-supervised visual pretraining, discovers discrete skills through information-bottleneck-guided vector quantization, and performs hierarchical probabilistic inference for robust progress estimation and verified counting on real-world factory data. |
|
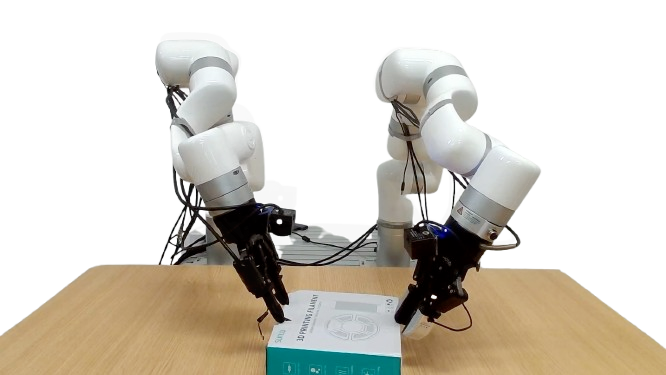
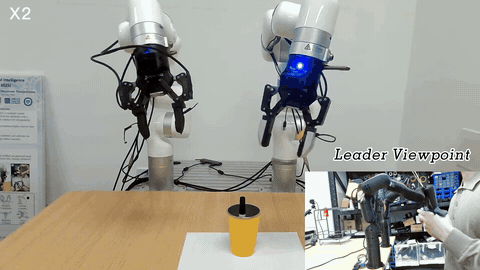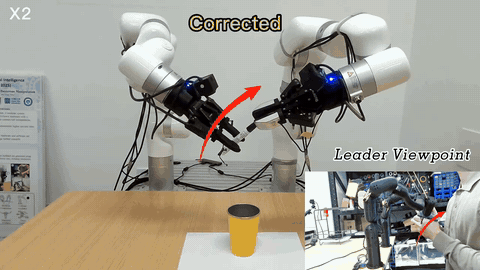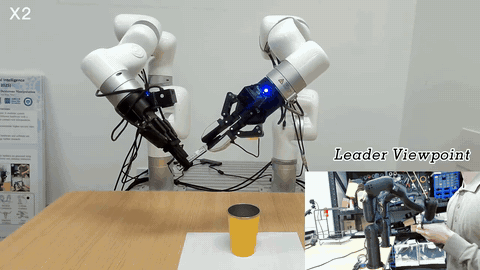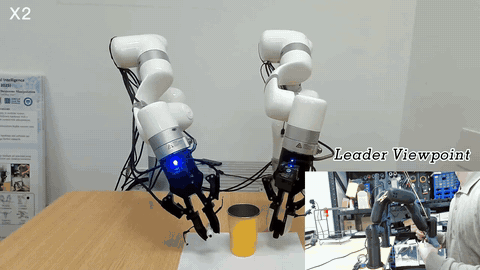
Peng Zhou, Zhongxuan Li, Jinsong Wu, Jiaming Qi, Jun Hu, David Navarro-Alarcon, Jia Pan, Lihua Xie, Shiyao Zhang, Zeqing Zhang arXiv preprint, 2026 arXiv / video We present a failure-aware bimanual teleoperation framework that provides compliant haptic assistance while preserving continuous human authority. Learned purely from mixed successful and failed offline teleoperation data, a conservative success score modulates the assistance strength while a learned actor supplies the corrective direction, both rendered through a master-side joint-space impedance interface that steers the operator away from risky actions without overriding intent. |
|
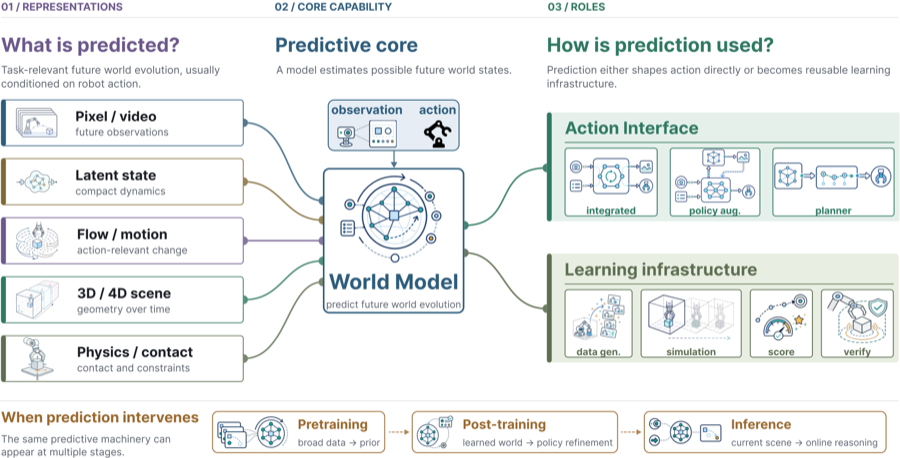
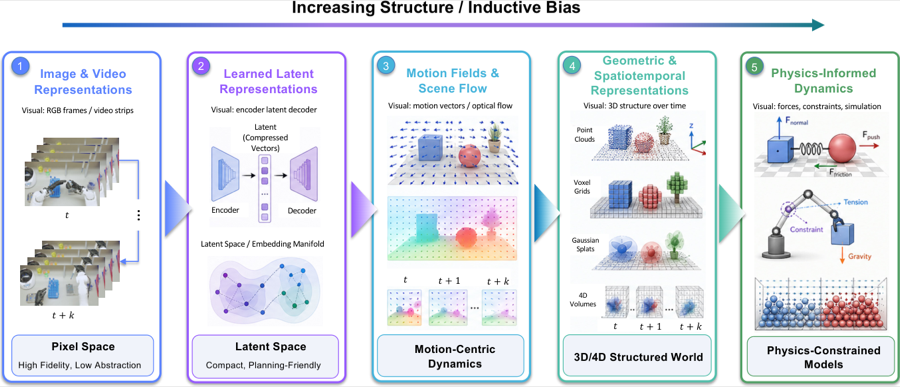
Fangyuan Wang*, Ziyuan Wang*, Guorui Pei, Mengshi Zhang, Canxi Liang, Jun Hu, Zhongxuan Li, Jinsong Wu, Ning Han, Zeqing Zhang, Jiaming Qi, Hongmin Wu, Shiyao Zhang, Pai Zheng, Jia Pan, David Navarro-Alarcon, Sichao Liu, Peng Zhou SmartBot, 2026 paper / arXiv We survey world models for robotic manipulation, operationally defining a world model as an action-conditioned predictive system. The literature is organized by what is predicted (five representation families), how prediction connects to action (integrated prediction–action models vs. explicit predictive planners), and when prediction is used across pretraining, post-training, and inference. |
|
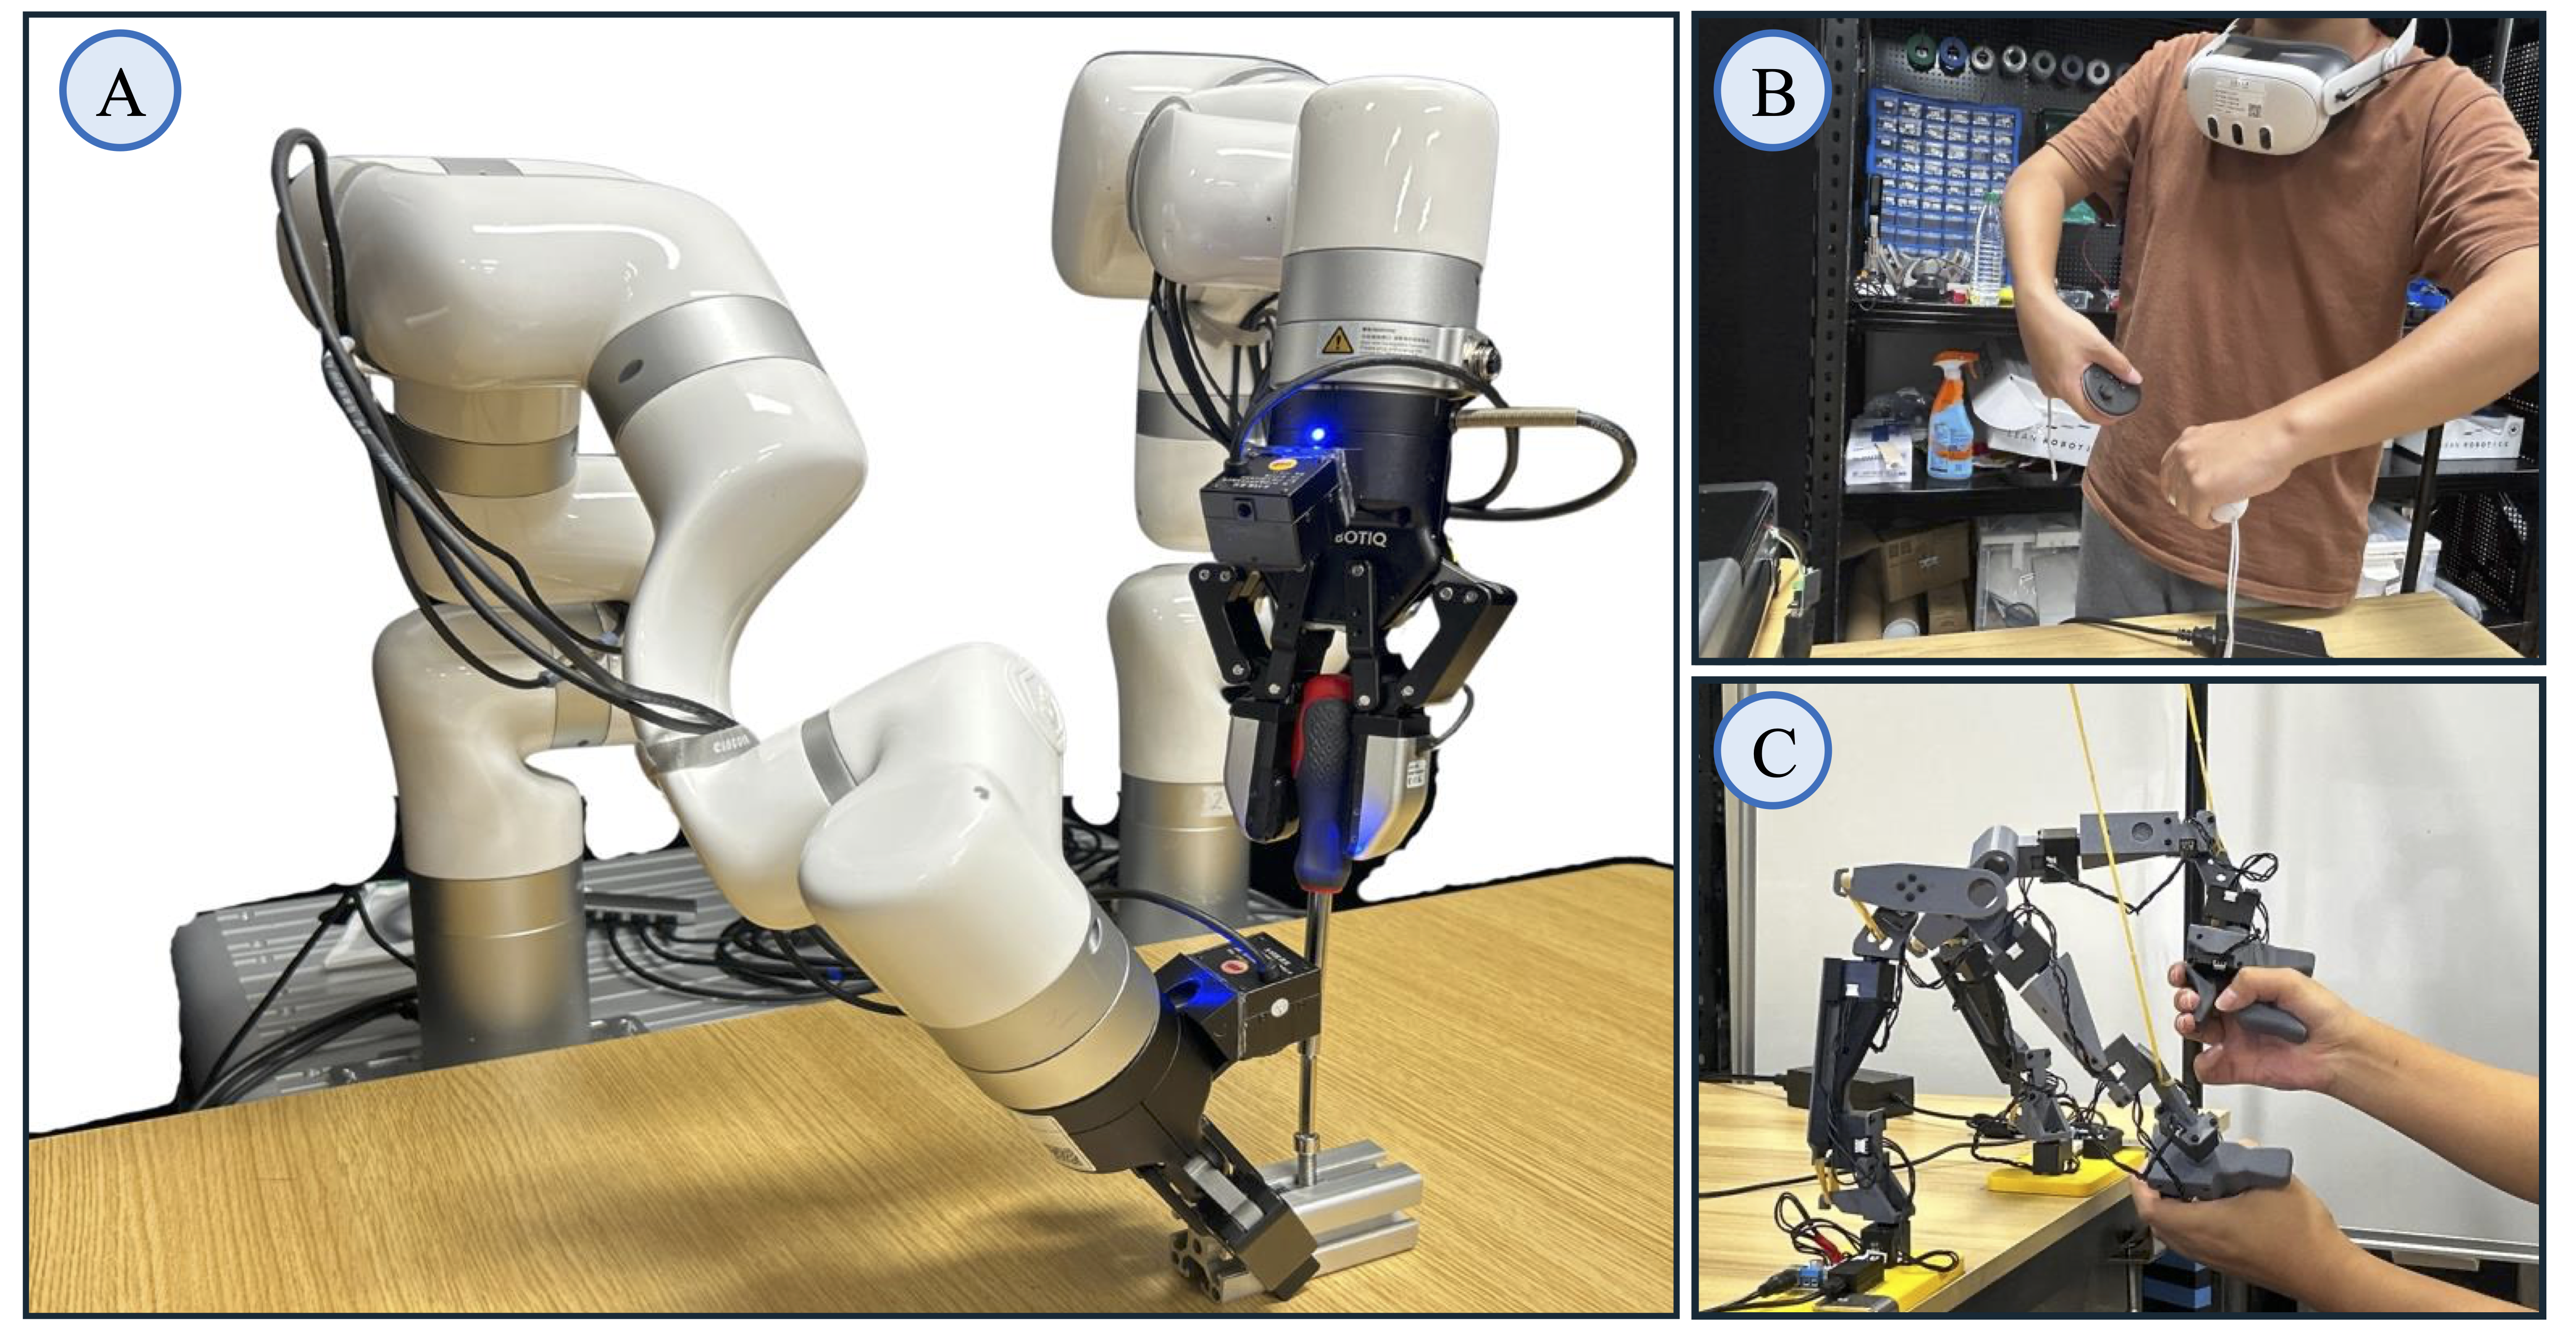
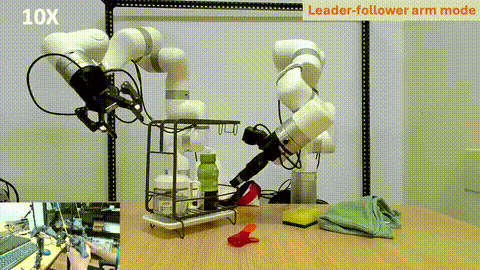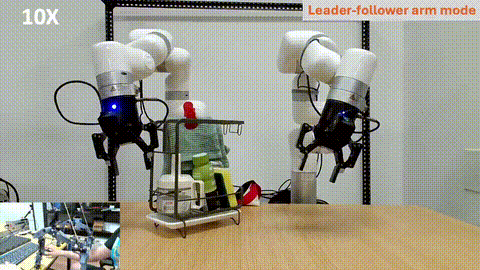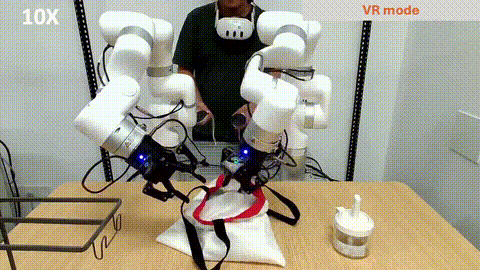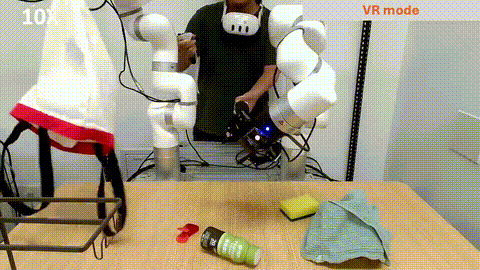
Zhongxuan Li, Zeliang Guo, Jun Hu, David Navarro-Alarcon, Jia Pan, Hongmin Wu, Peng Zhou IEEE International Conference on Robotics and Biomimetics (ROBIO), Best Paper Finalist, 2025 paper / project page We present UniBiDex, a unified teleoperation framework for robotic bimanual dexterous manipulation that supports both VR-based and leader–follower input modalities. The framework integrates heterogeneous input devices into a shared control stack with consistent kinematic treatment and safety guarantees, employing null-space control to optimize bimanual configurations for smooth, collision-free motion. |
|
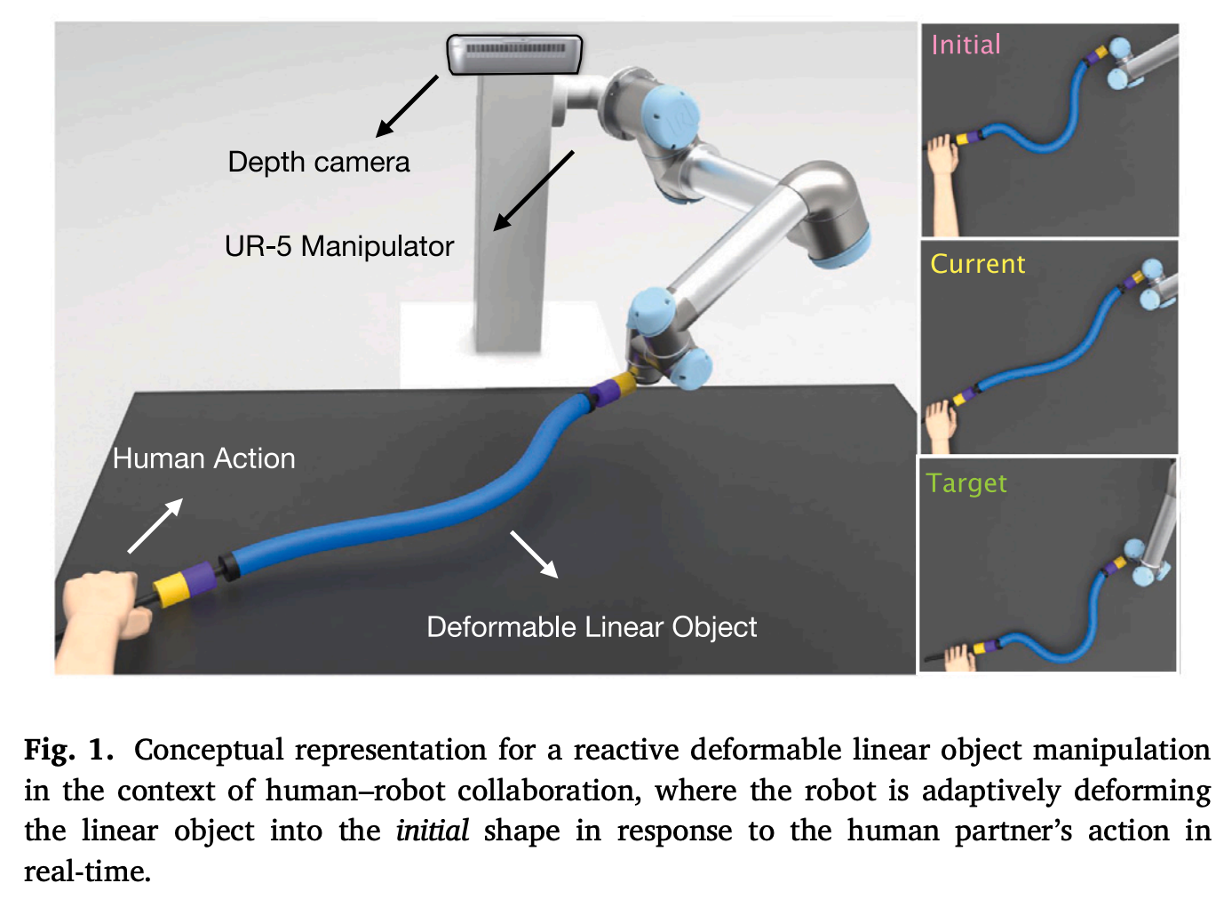
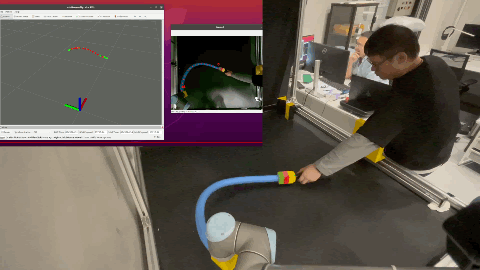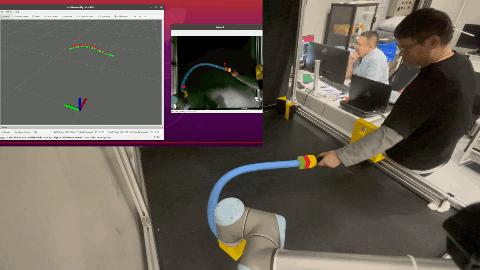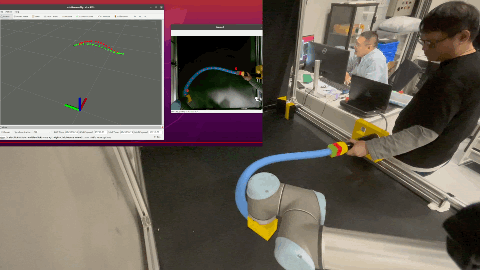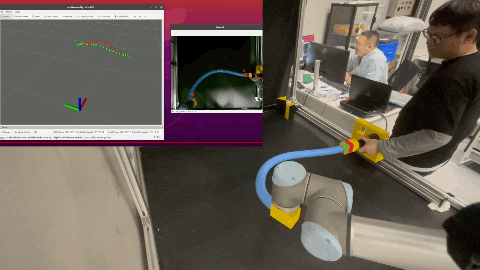
Peng Zhou, Pai Zheng, Jiaming Qi†, Chengxi Li, Hoi-Yin Lee, Anqing Duan, Liang Lu, Zhongxuan Li, Luyin Hu, David Navarro-Alarcon Robotics and Computer-Integrated Manufacturing (RCIM), 2024 paper / project page We propose a new topological latent control model for reactive human–robot collaborative manipulation of deformable linear objects. The method achieves real-time collaborative control and has been recognized as an ESI Highly Cited + Hot Paper. |
|
|
|
Projects Before 2023
A collection of my earlier research projects and coursework from my undergraduate and early career studies. |
|
|
|
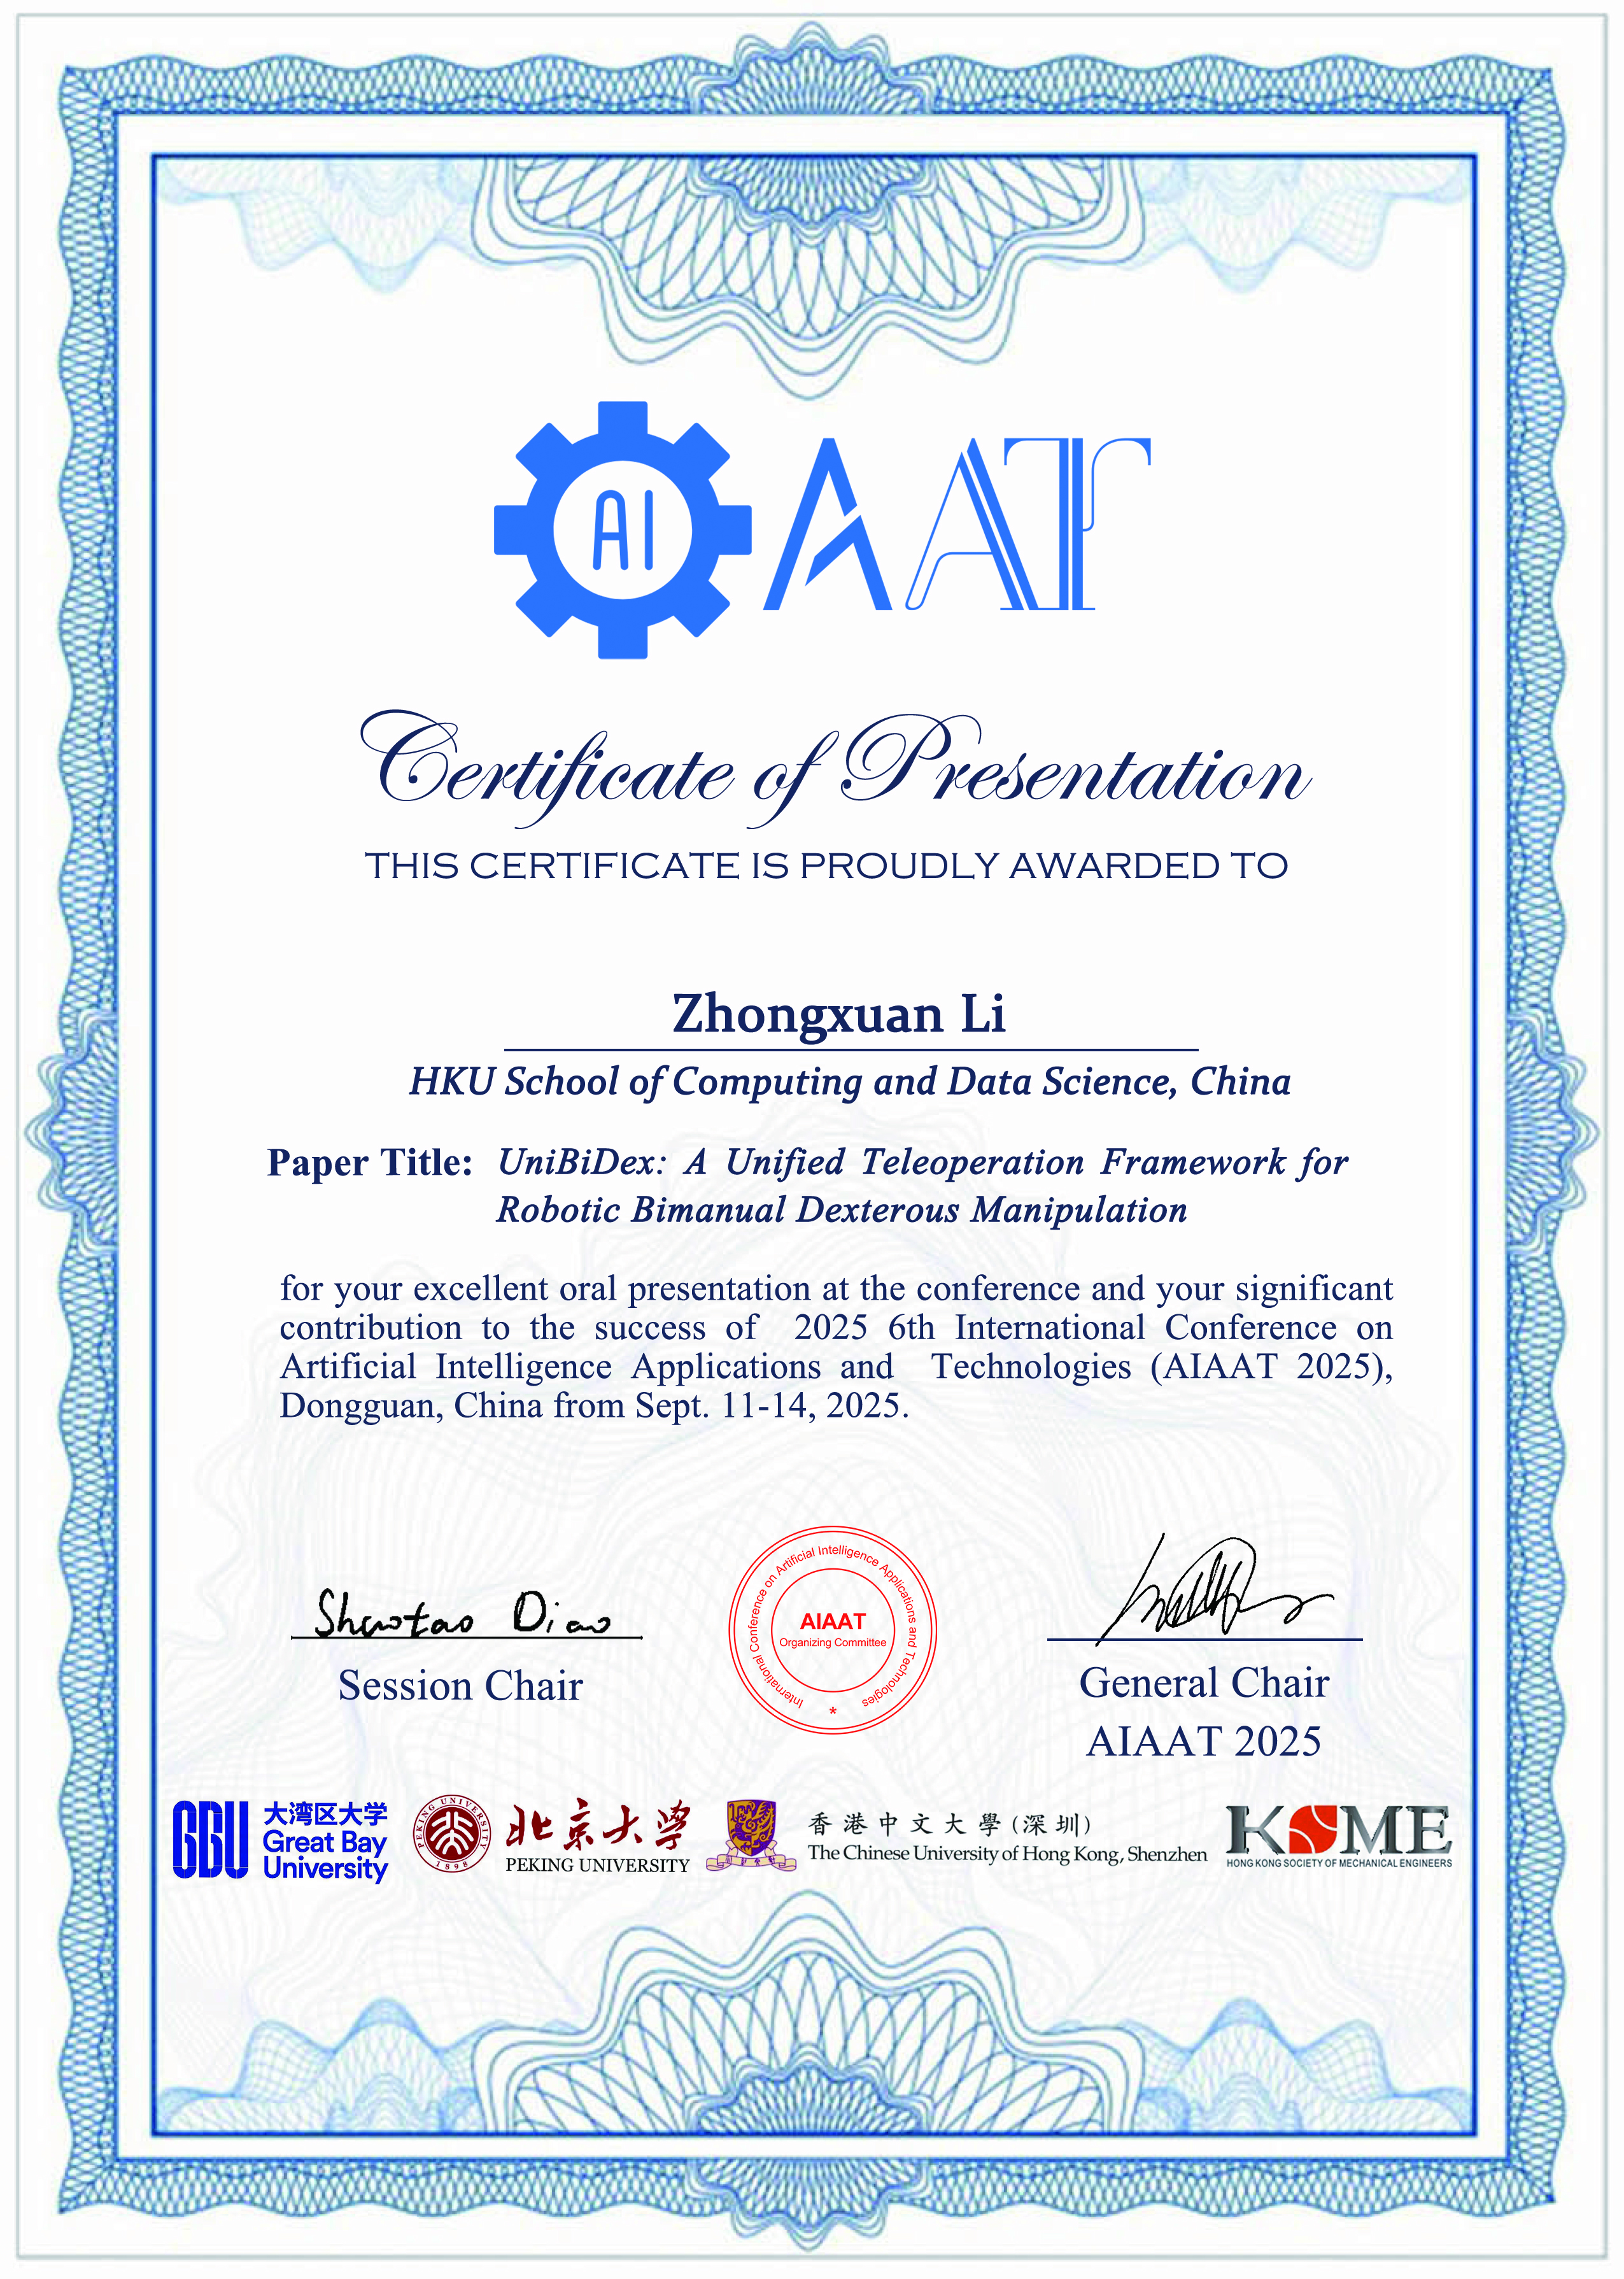
Poster Spotlight, 6th International Conference on Artificial Intelligence Applications and Technologies (AIAAT 2025)
Paper: "UniBiDex: A Unified Teleoperation Framework for Robotic Bimanual Dexterous Manipulation" Dongguan, China, Sept. 11-14, 2025 Our paper was selected for Poster Spotlight at AIAAT 2025, highlighting our research on unified teleoperation framework for robotic bimanual dexterous manipulation. |
|
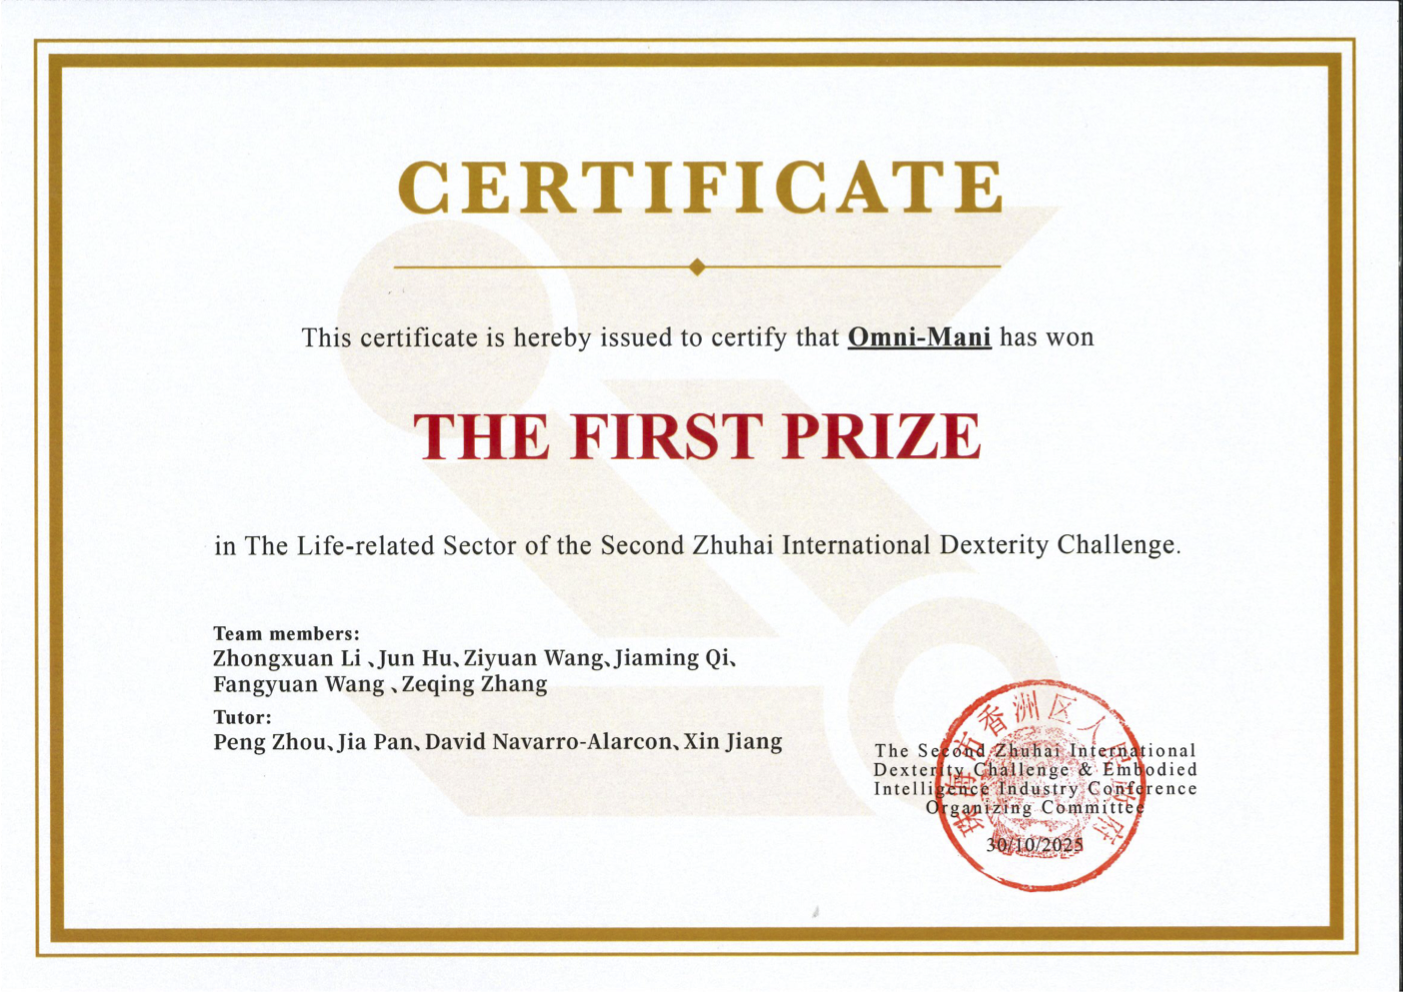
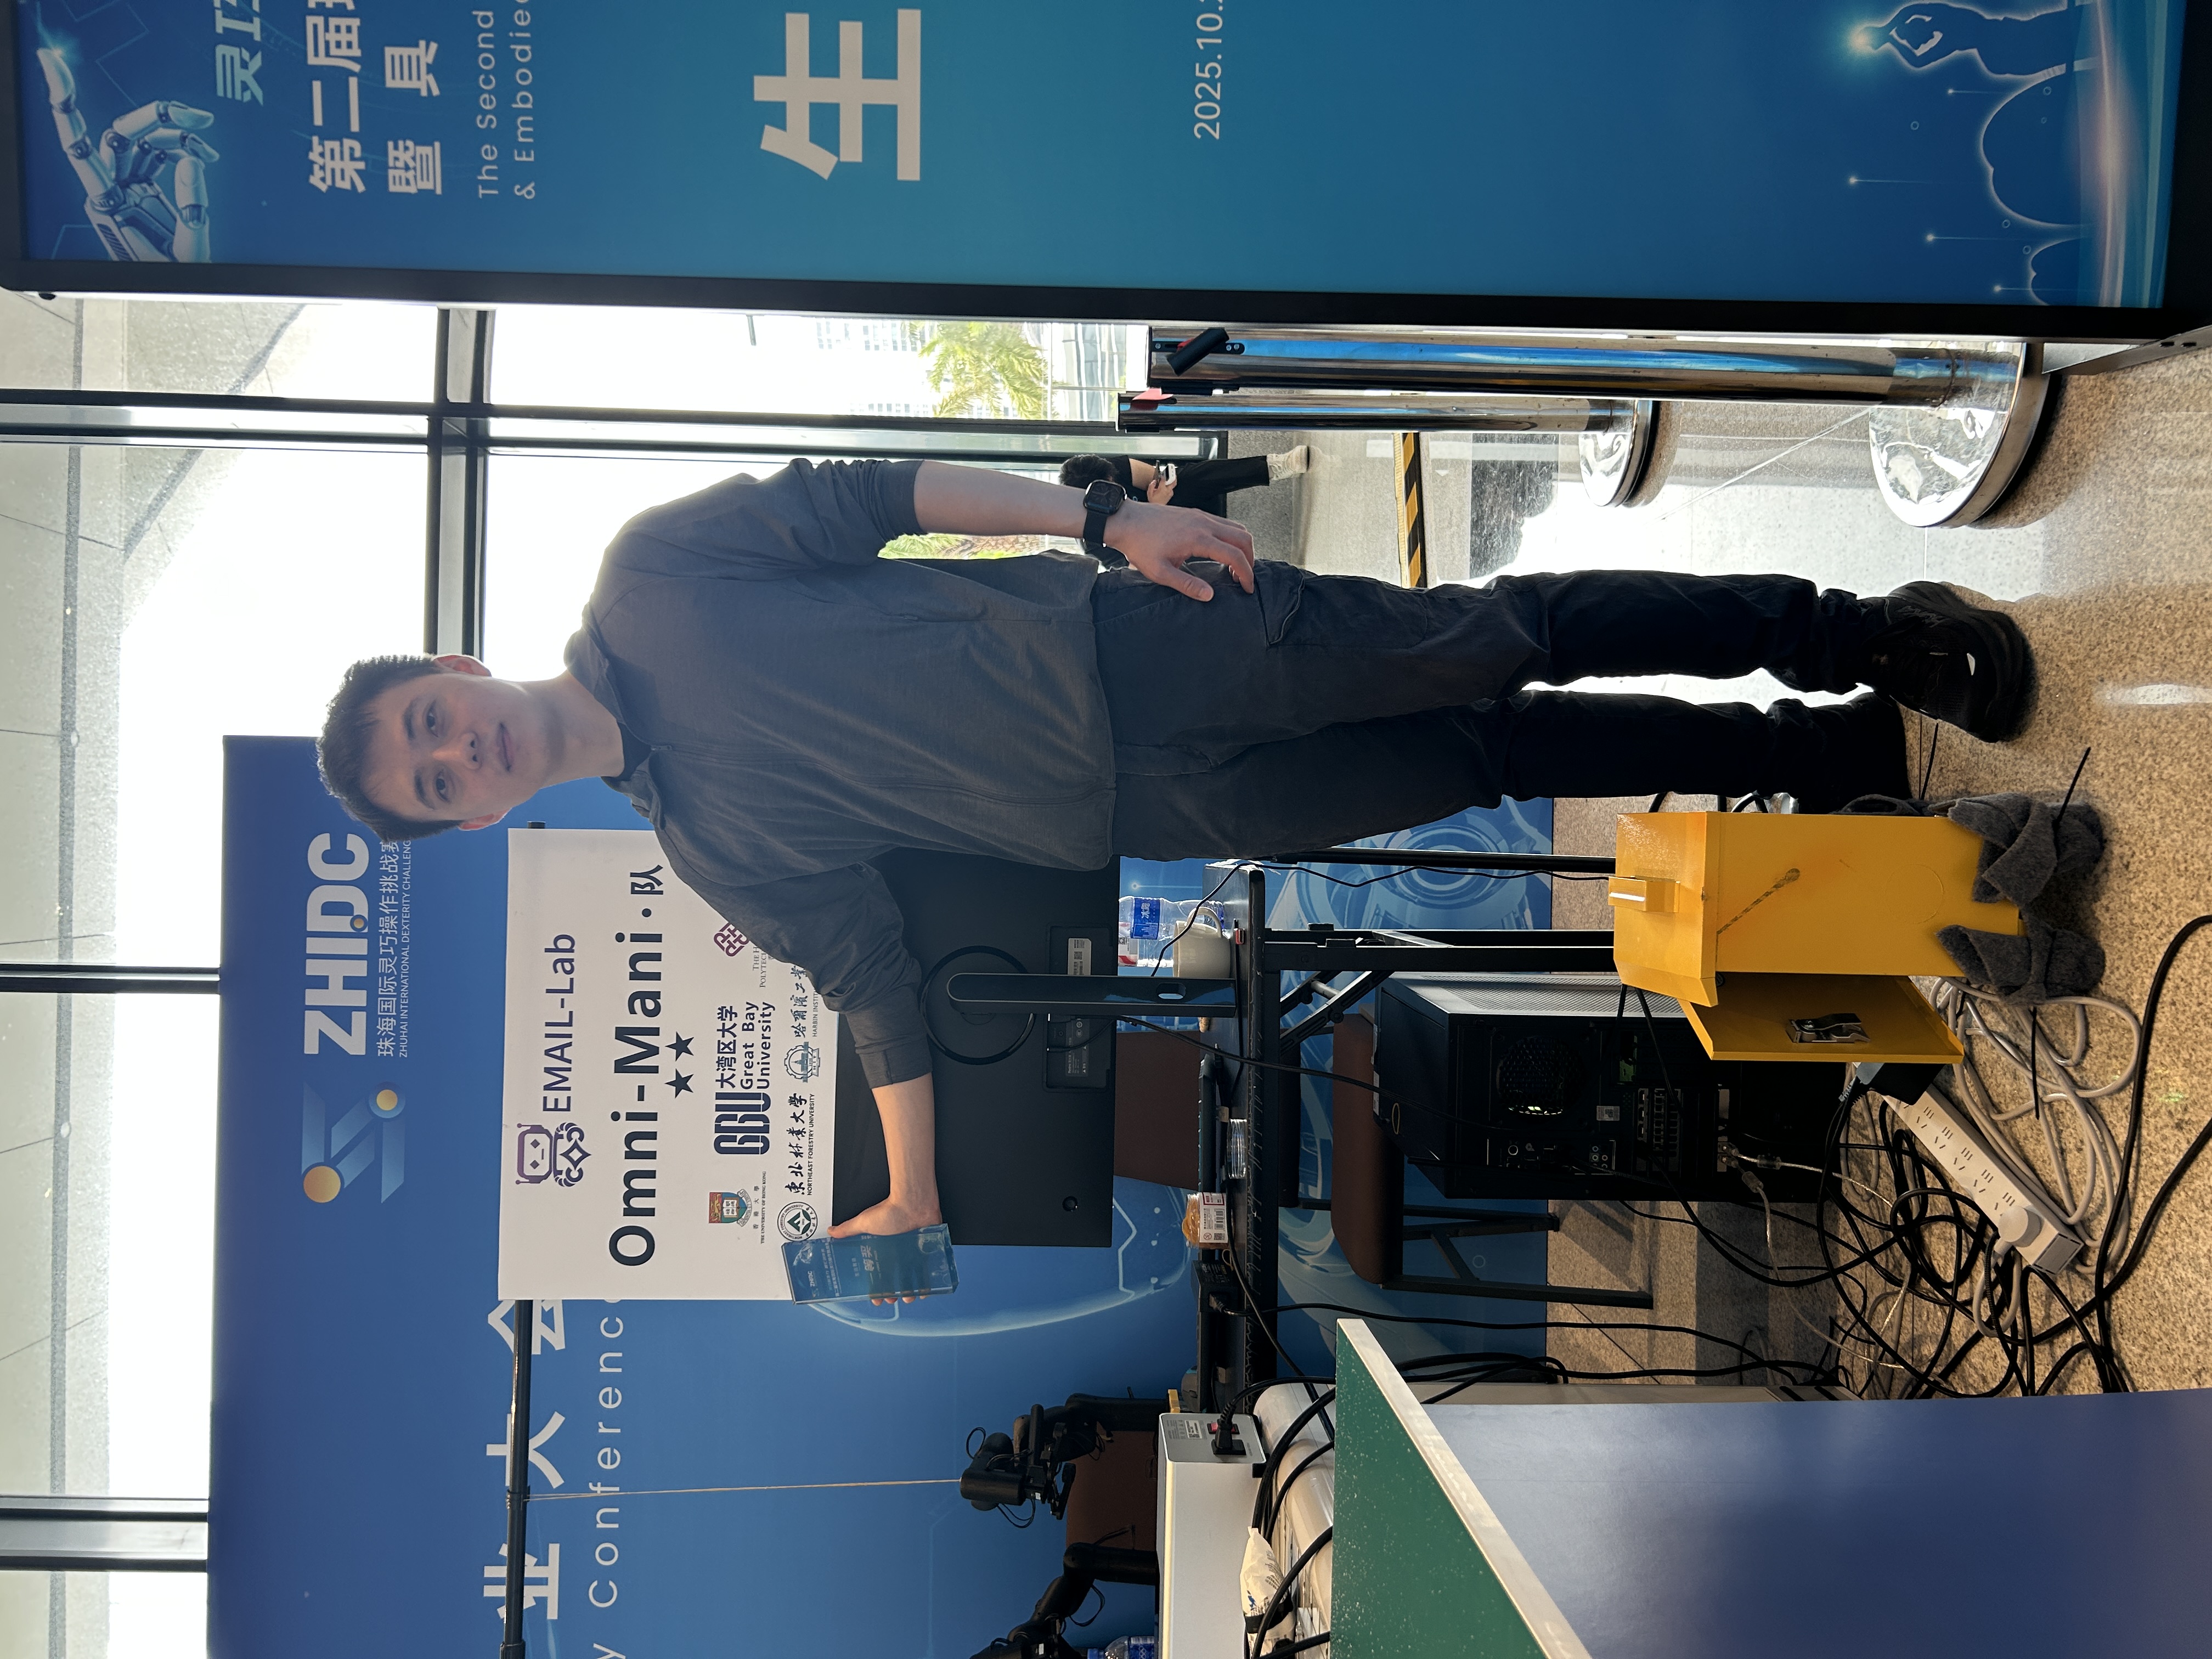
第二届珠海国际灵巧操作挑战赛-日常生活赛道(厨房人机协作场景)-第一名, 2025
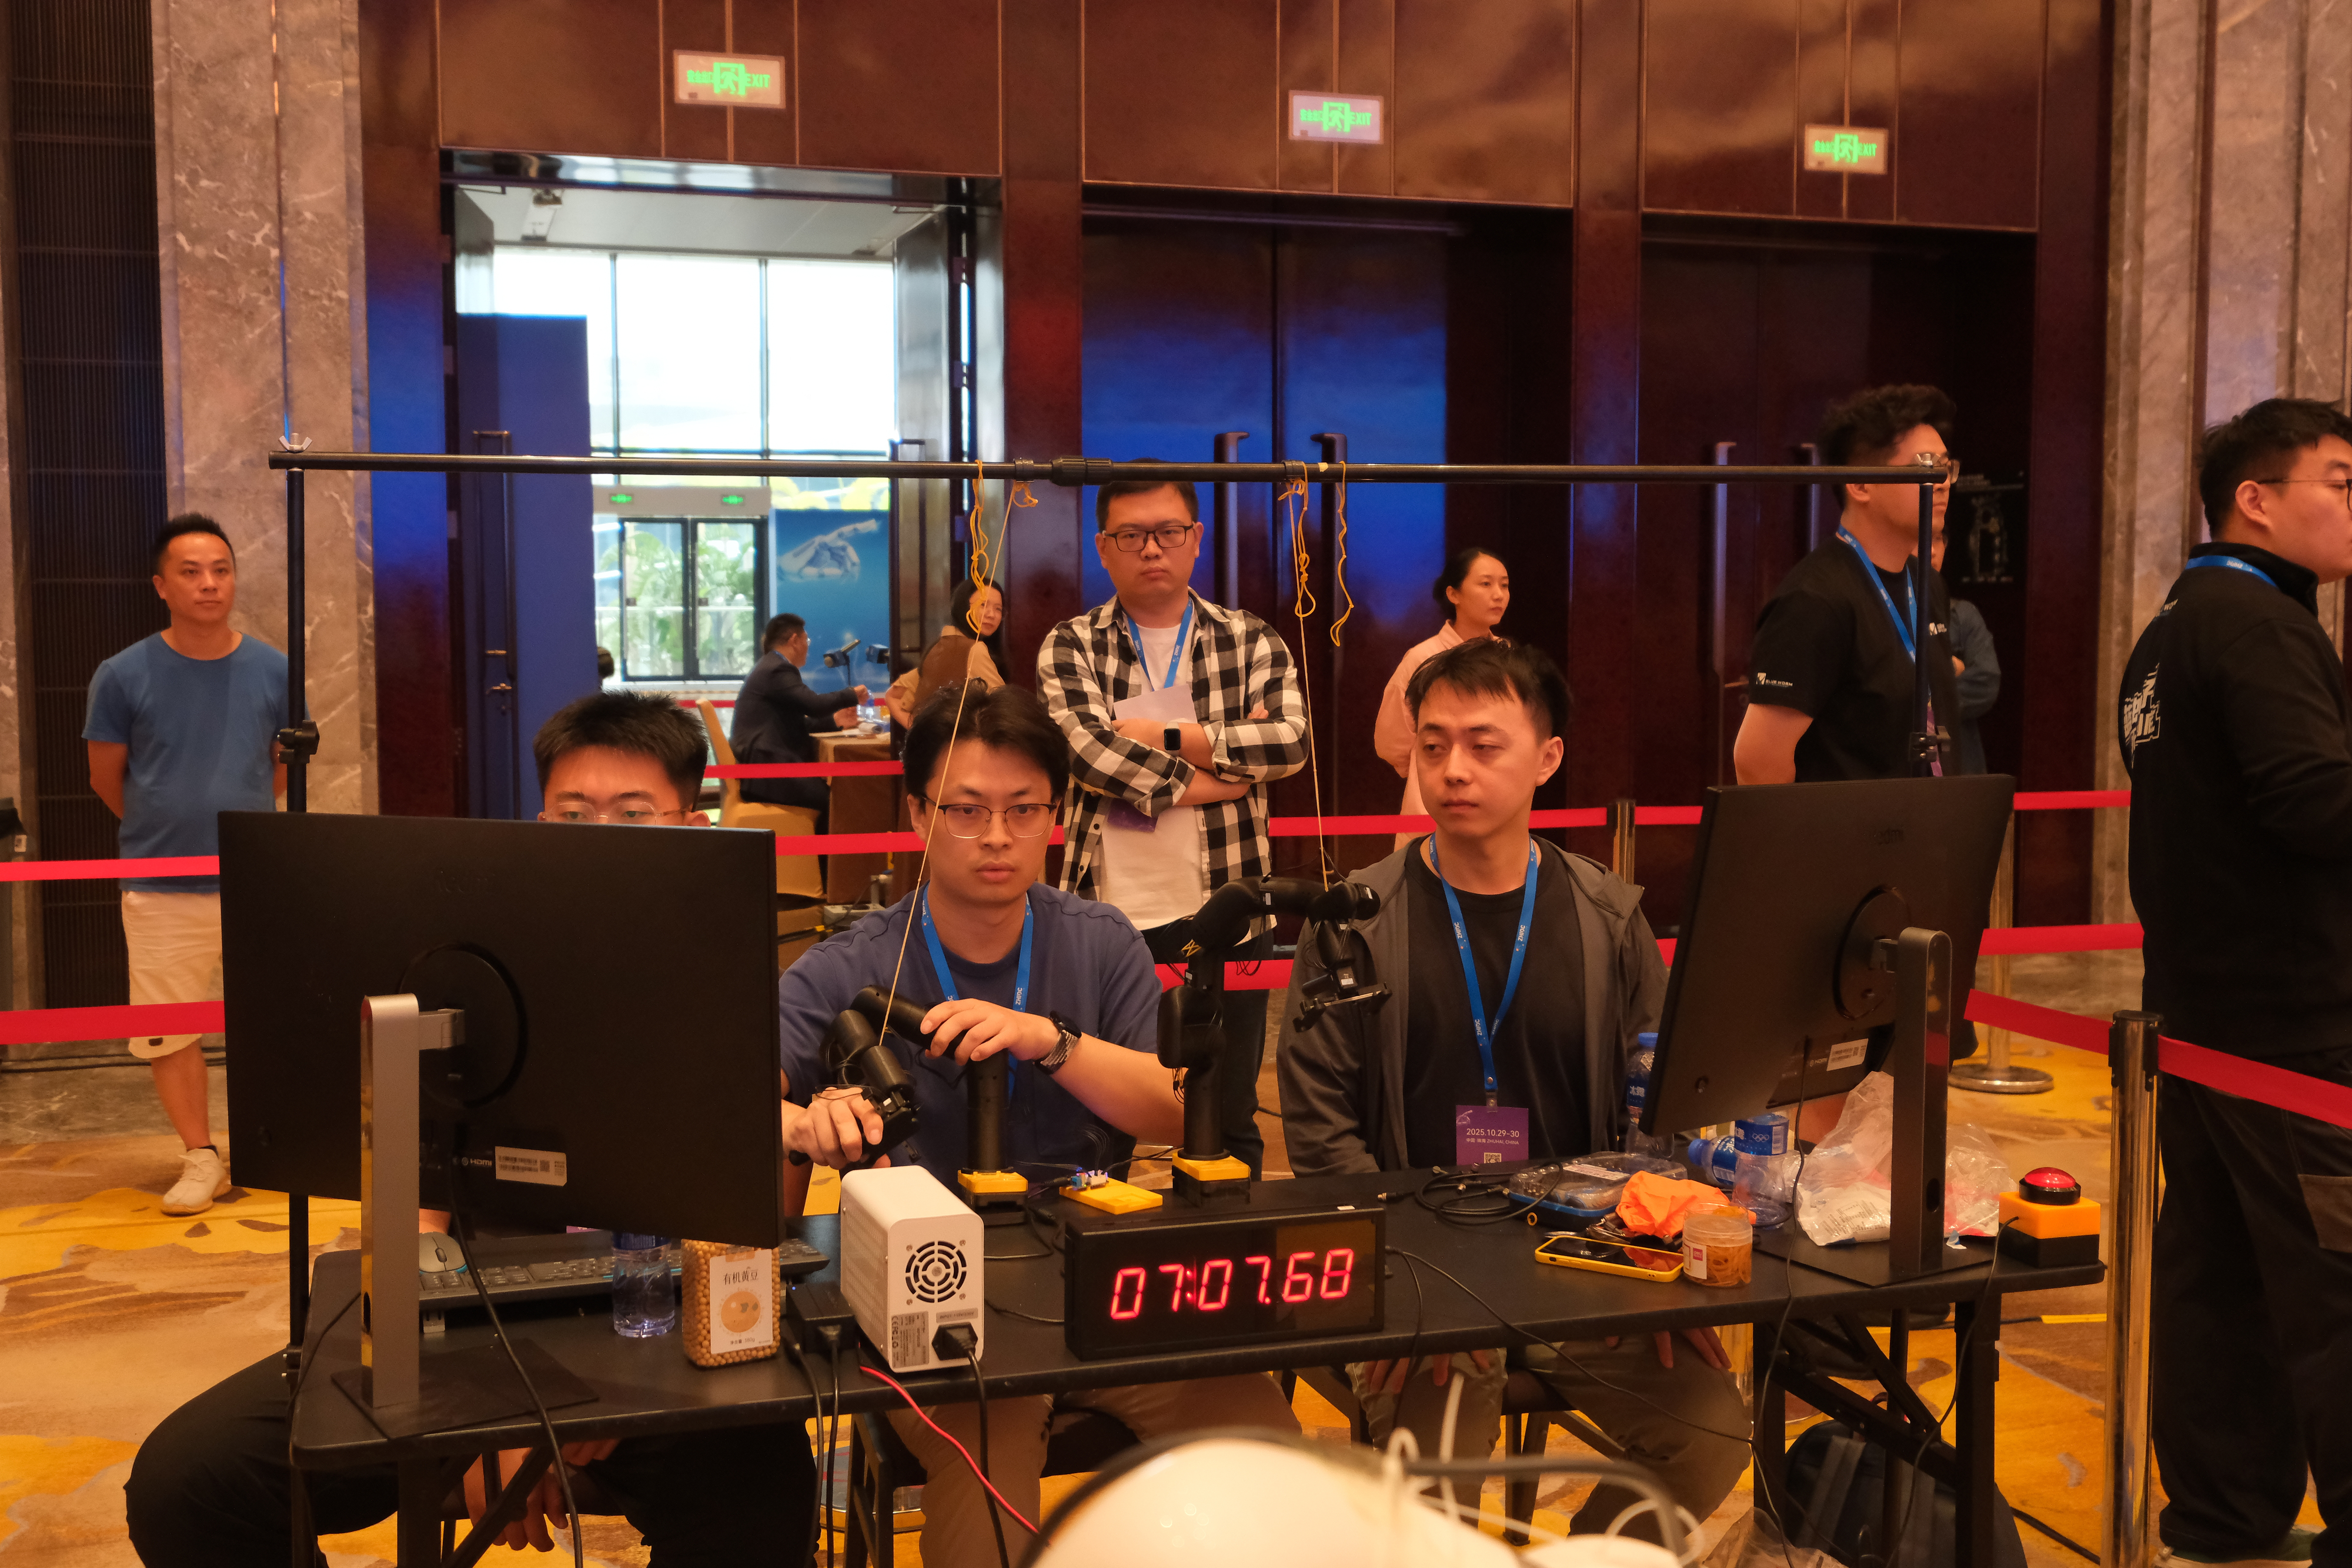
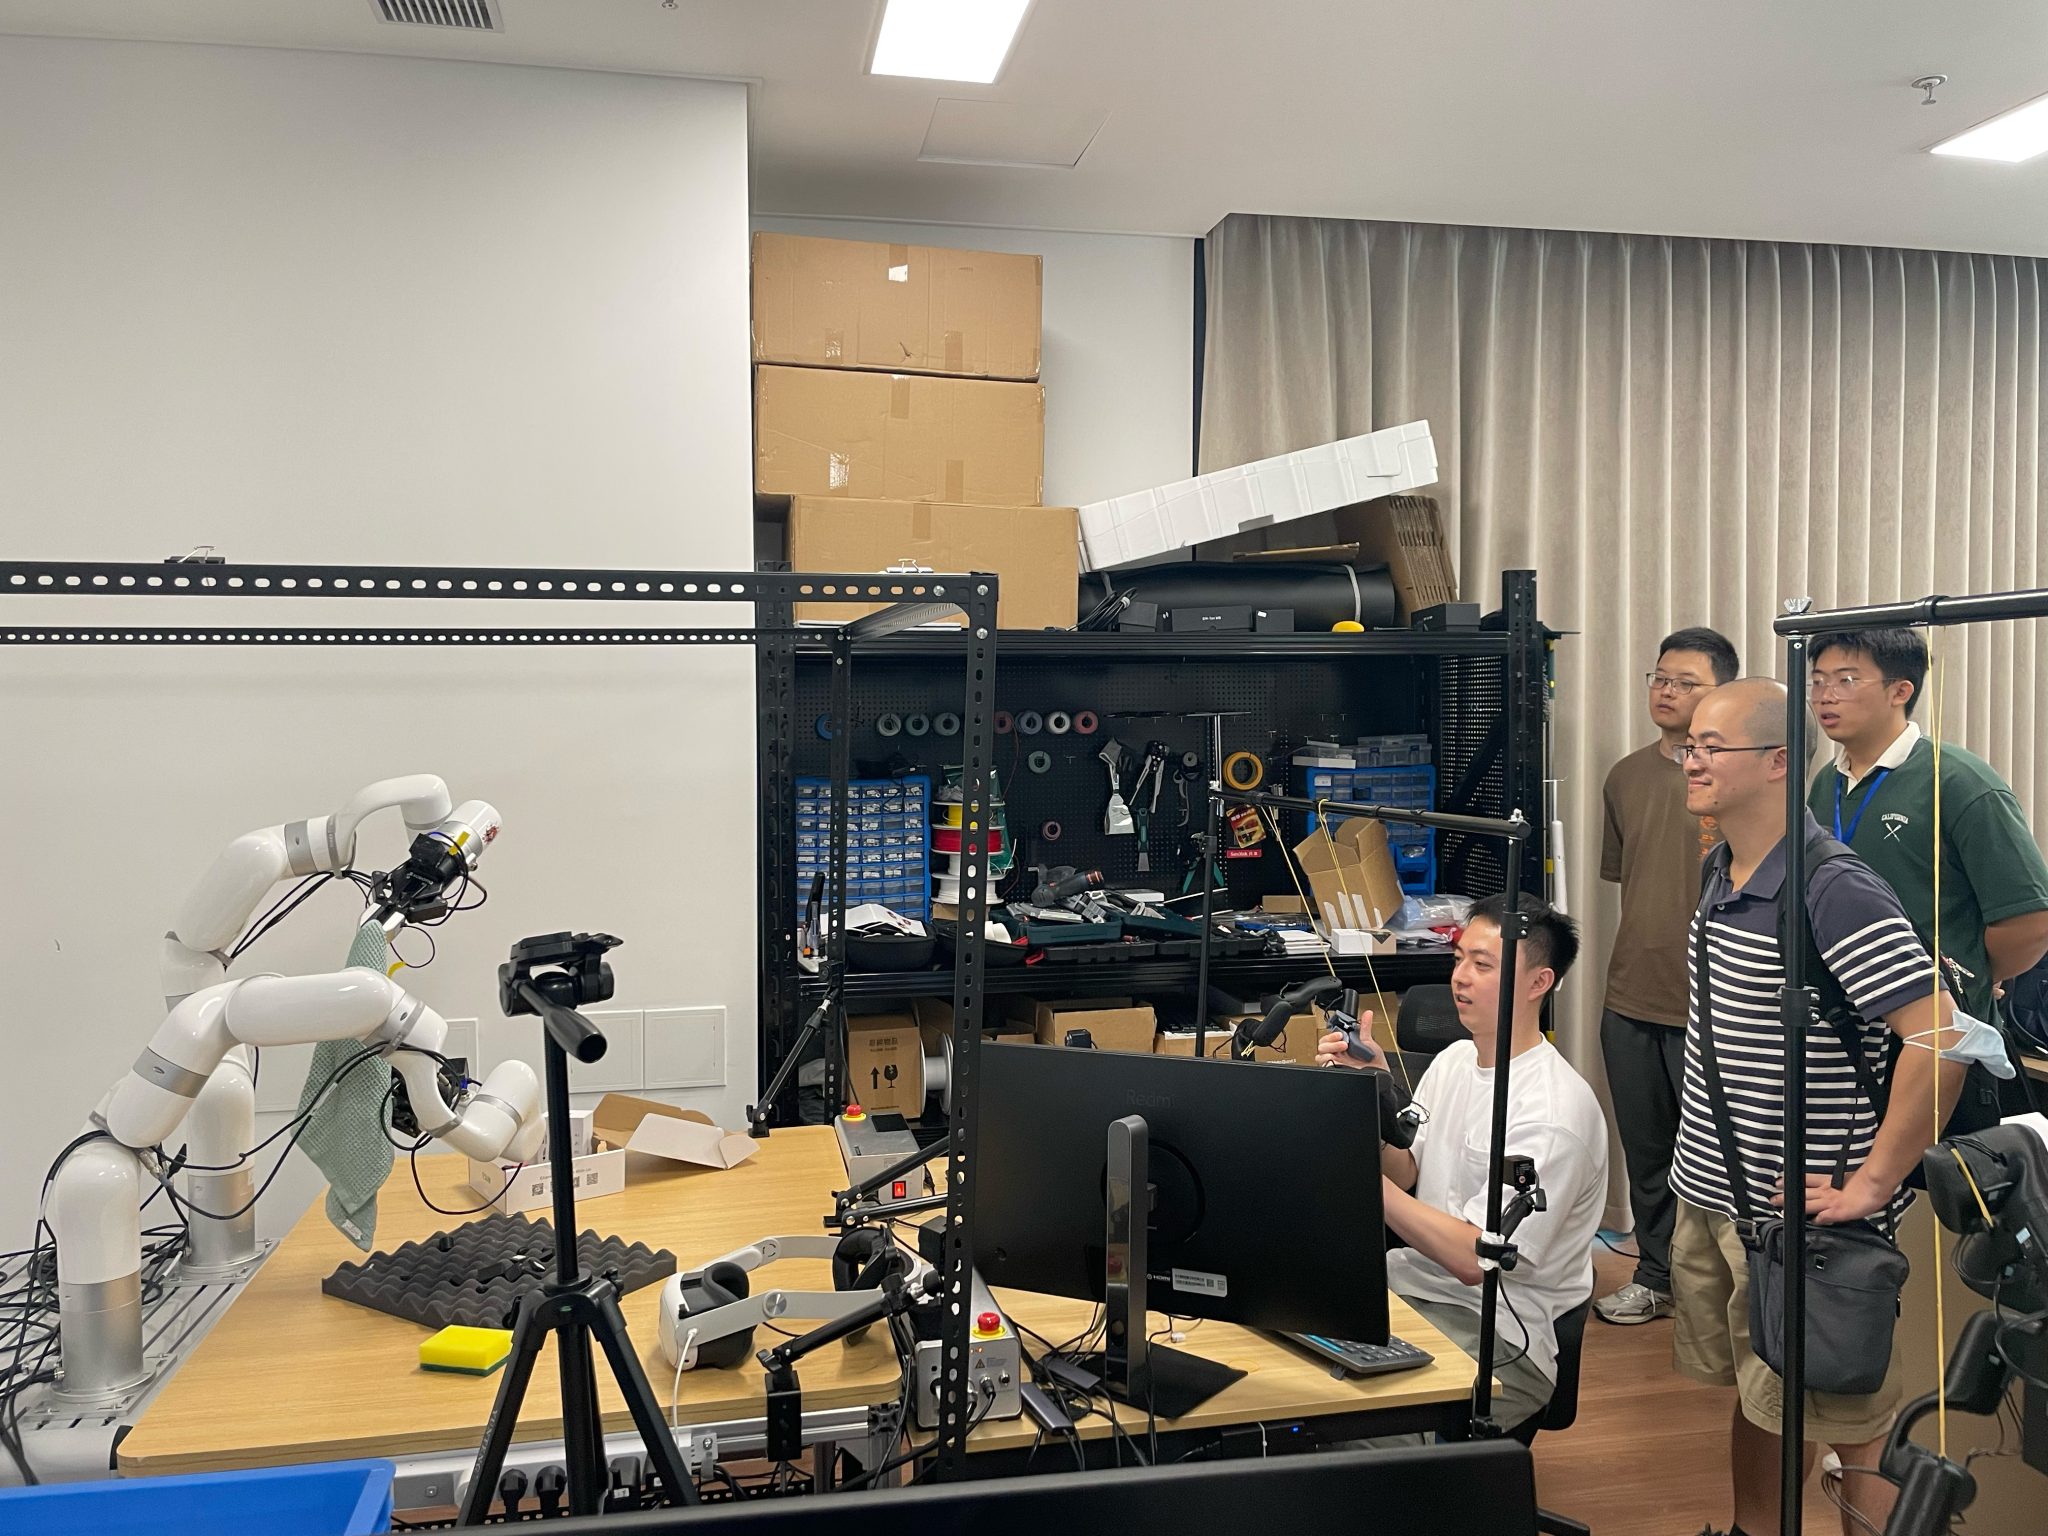
Championship Award (1st Place), 2nd Zhuhai International Dexterous Manipulation Challenge - Daily Life Track (Kitchen Human-Robot Collaboration Scenario) Prize: RMB 500,000 + RMB 6 Million Investment News Report / View Gallery As a key member of the Omni-Mani team led by Prof. Jia Pan (HKU), we secured the championship among 20 elite international teams. |
|
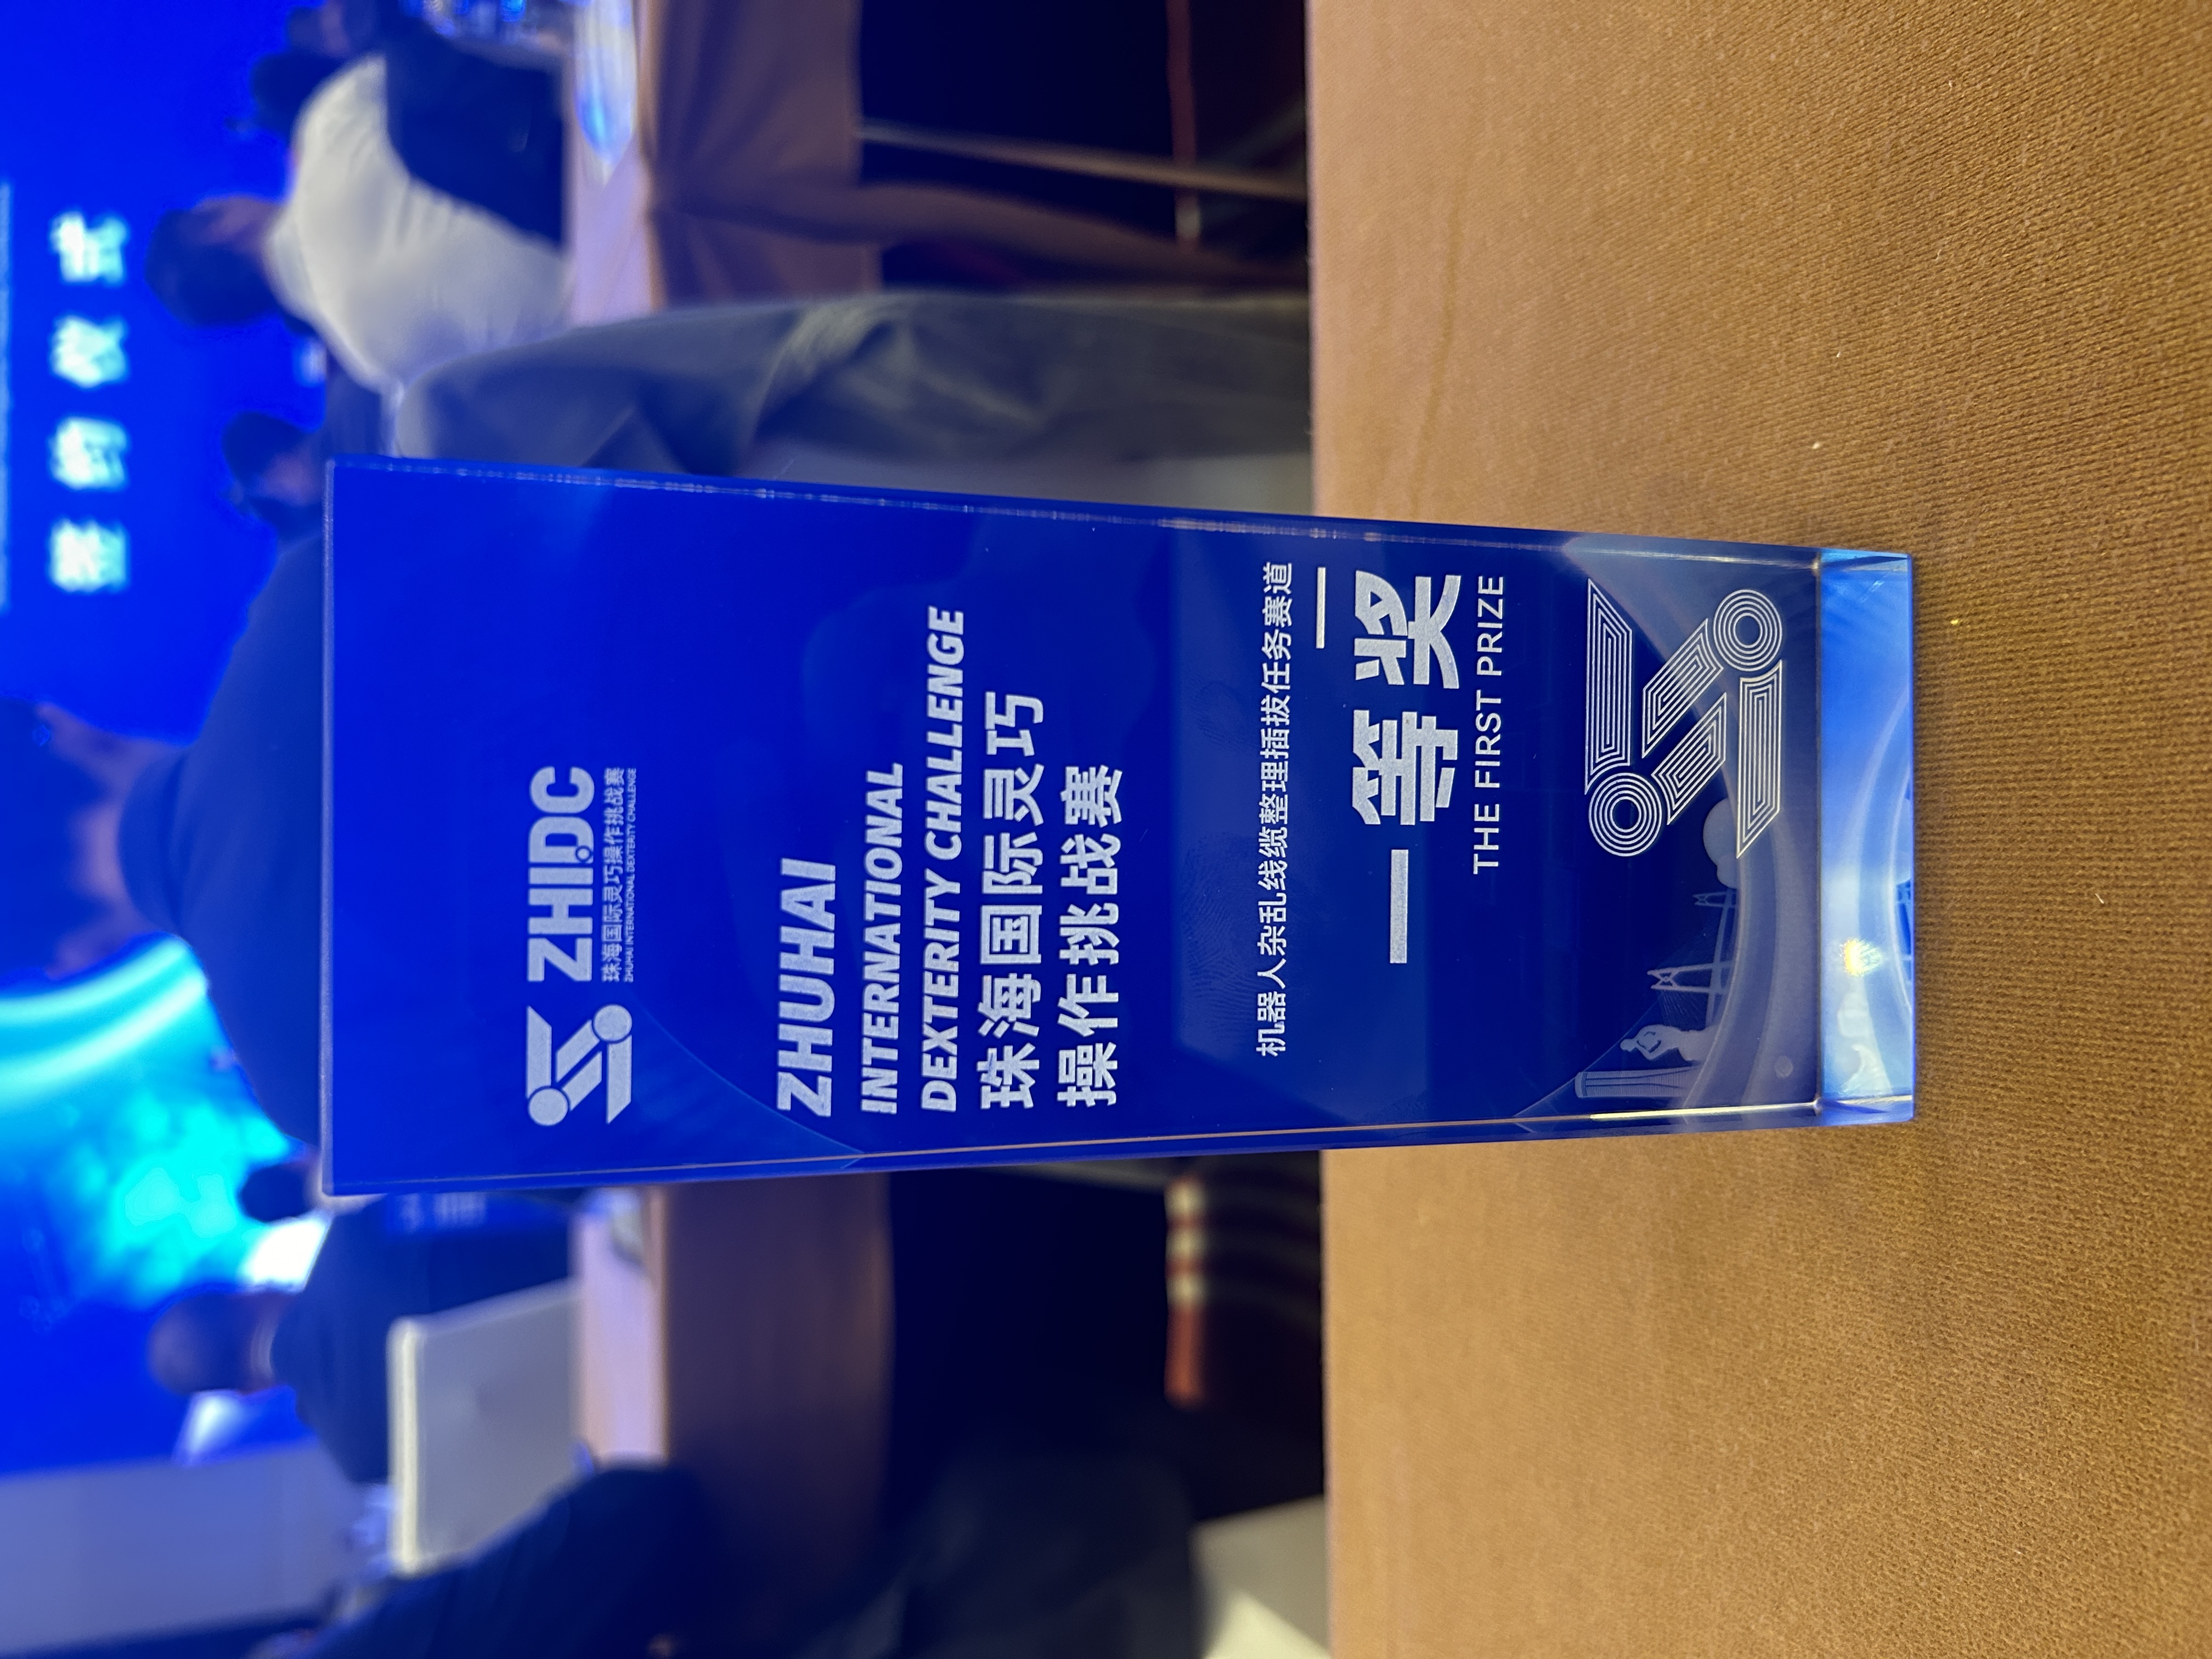
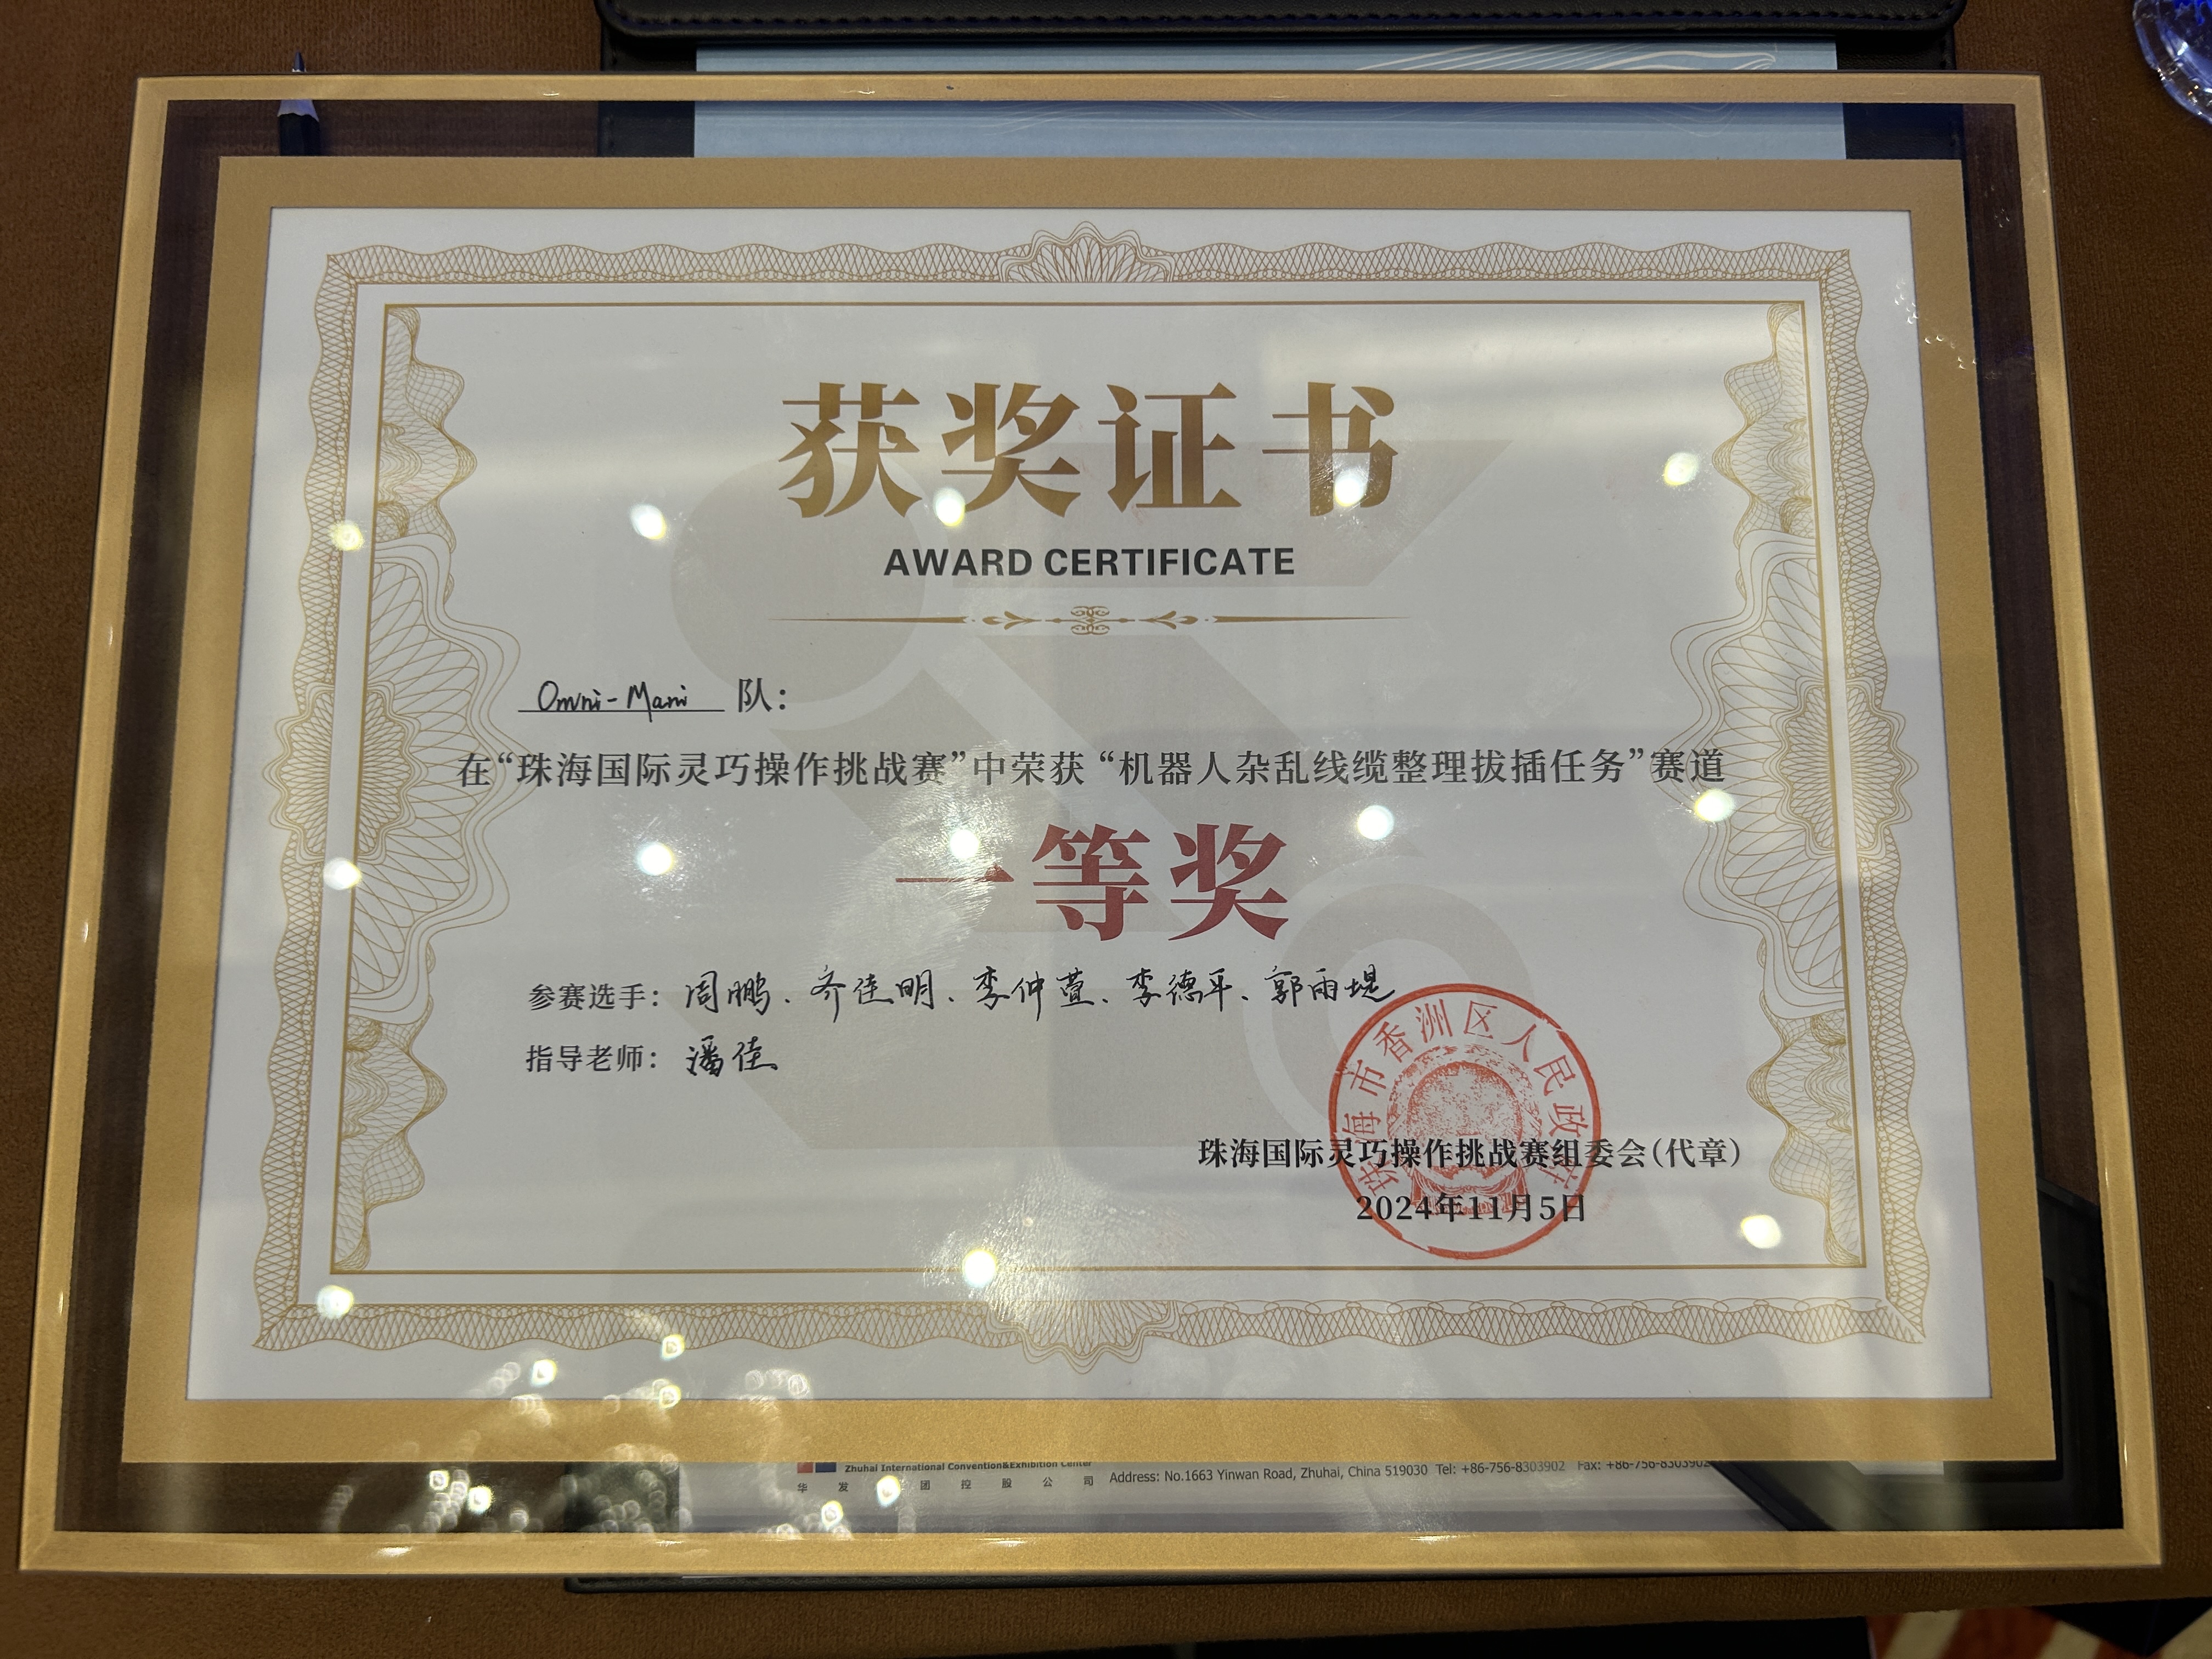
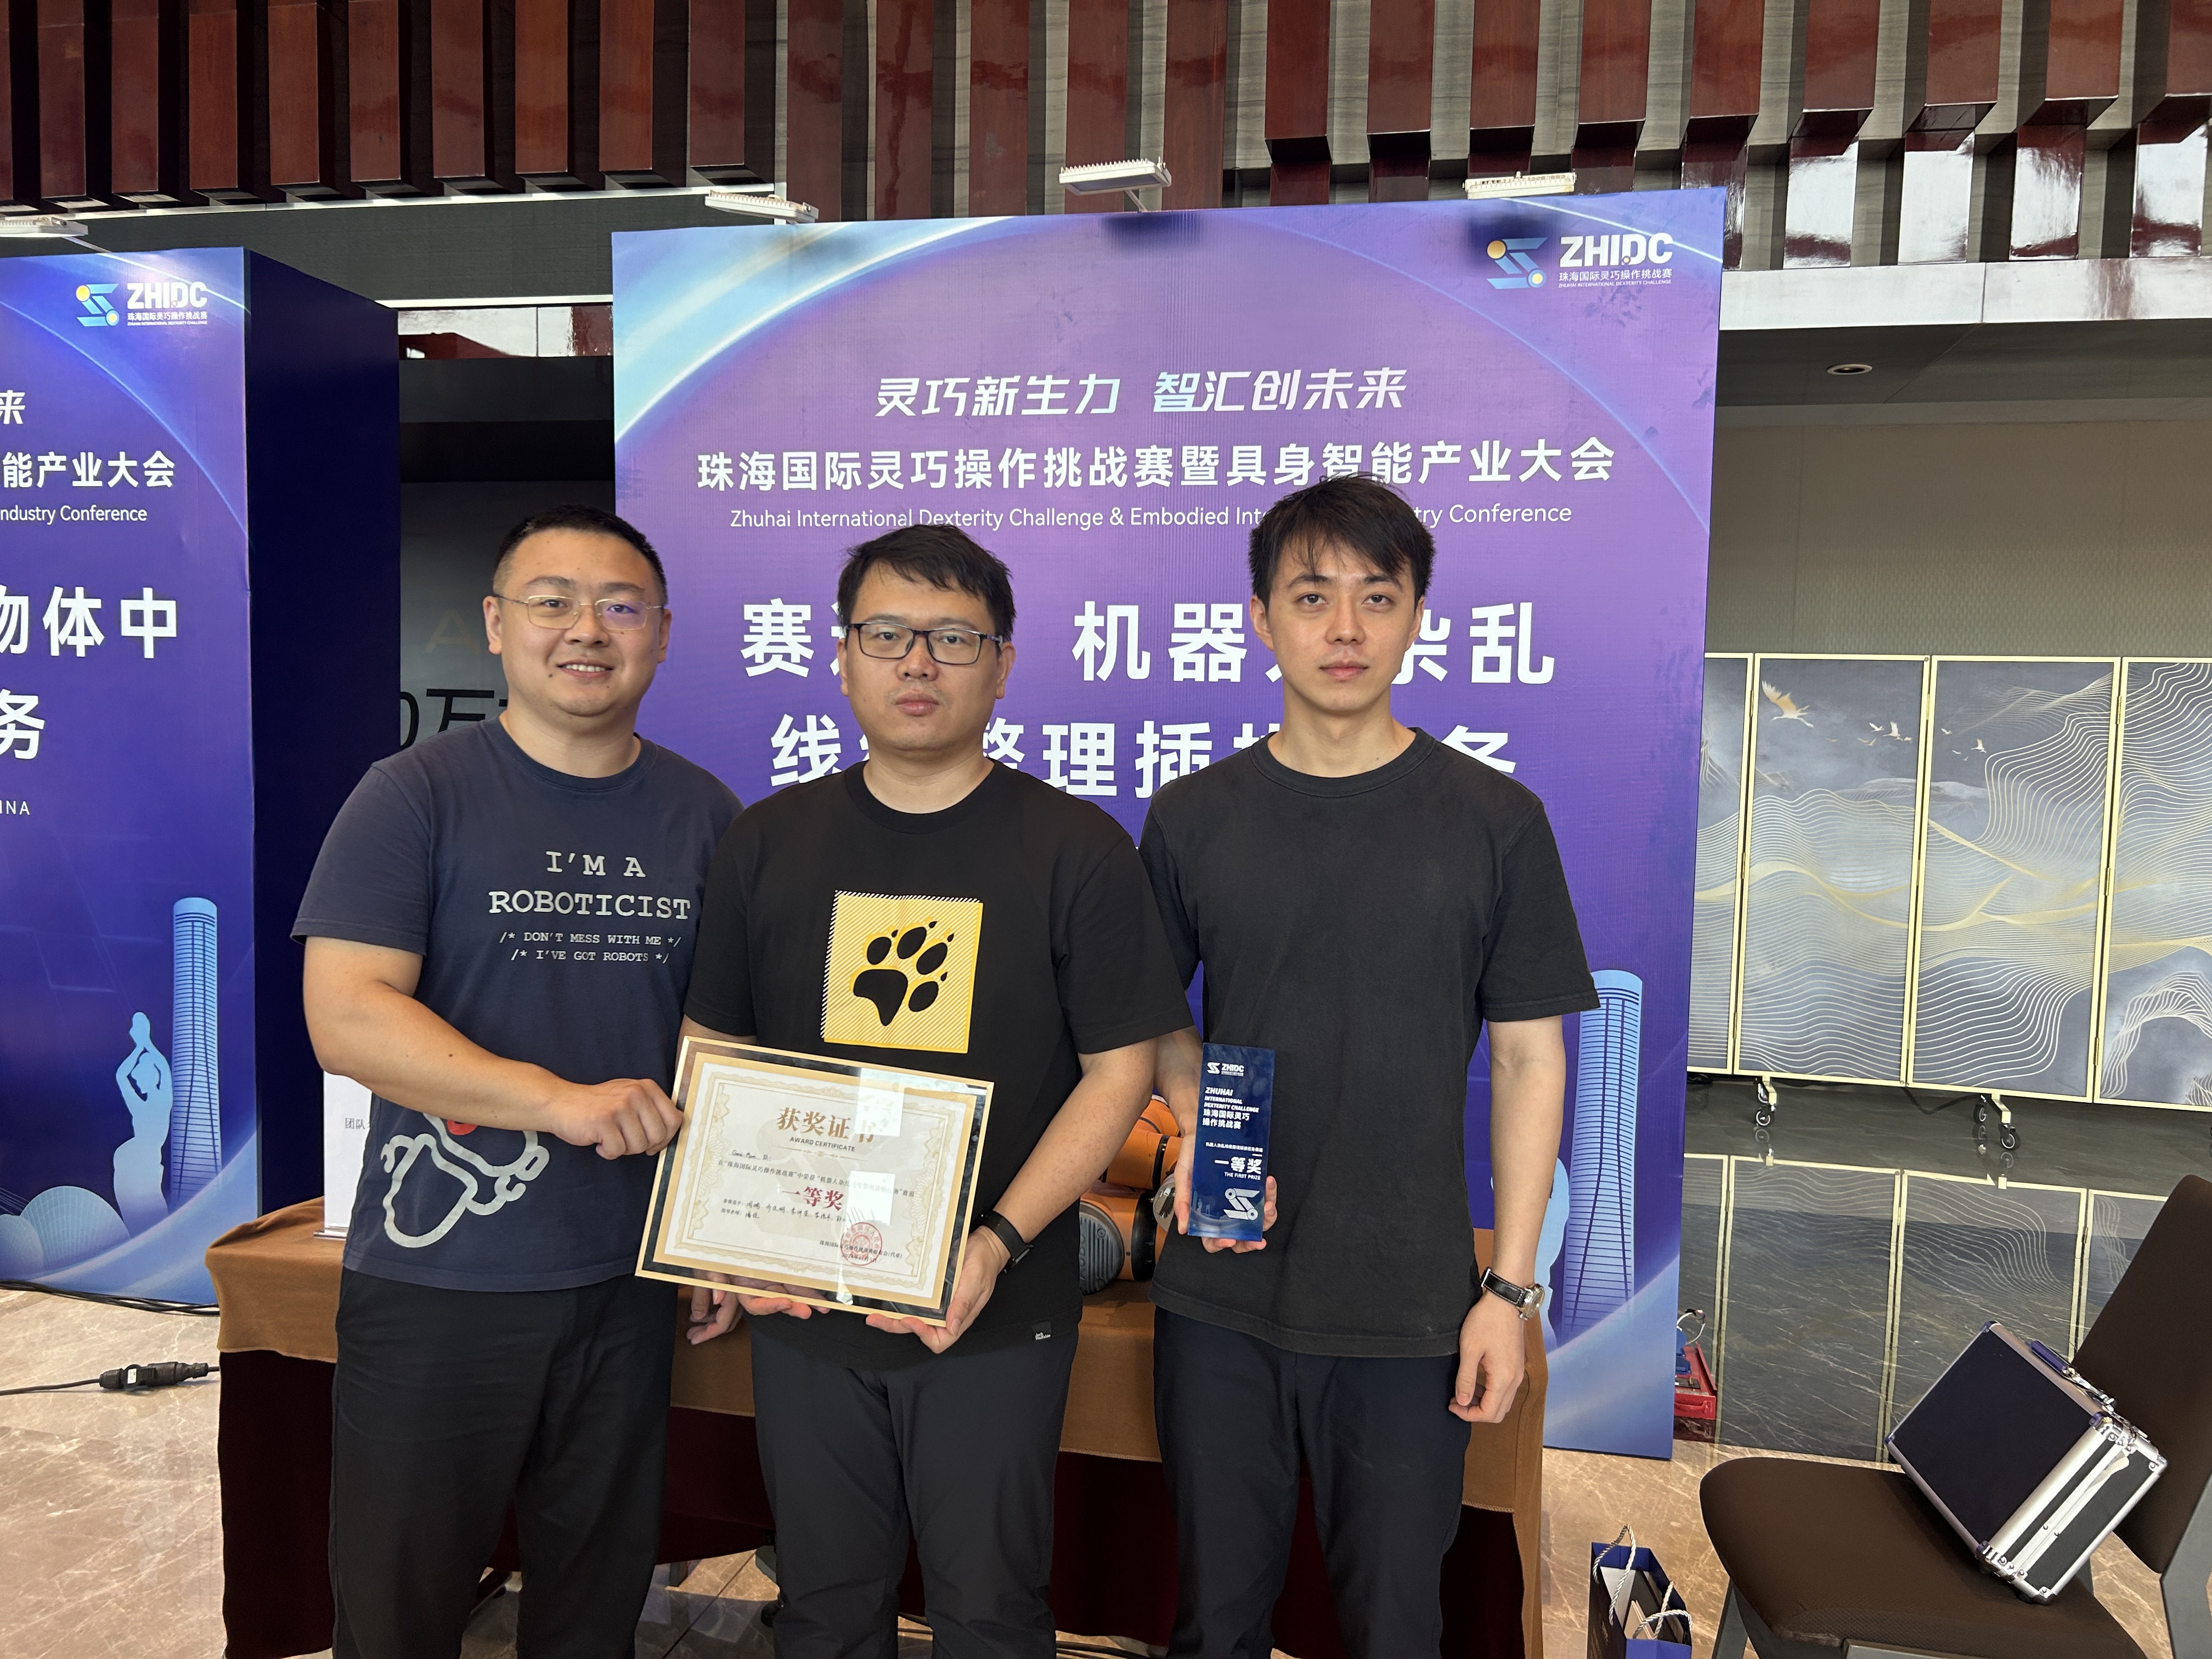
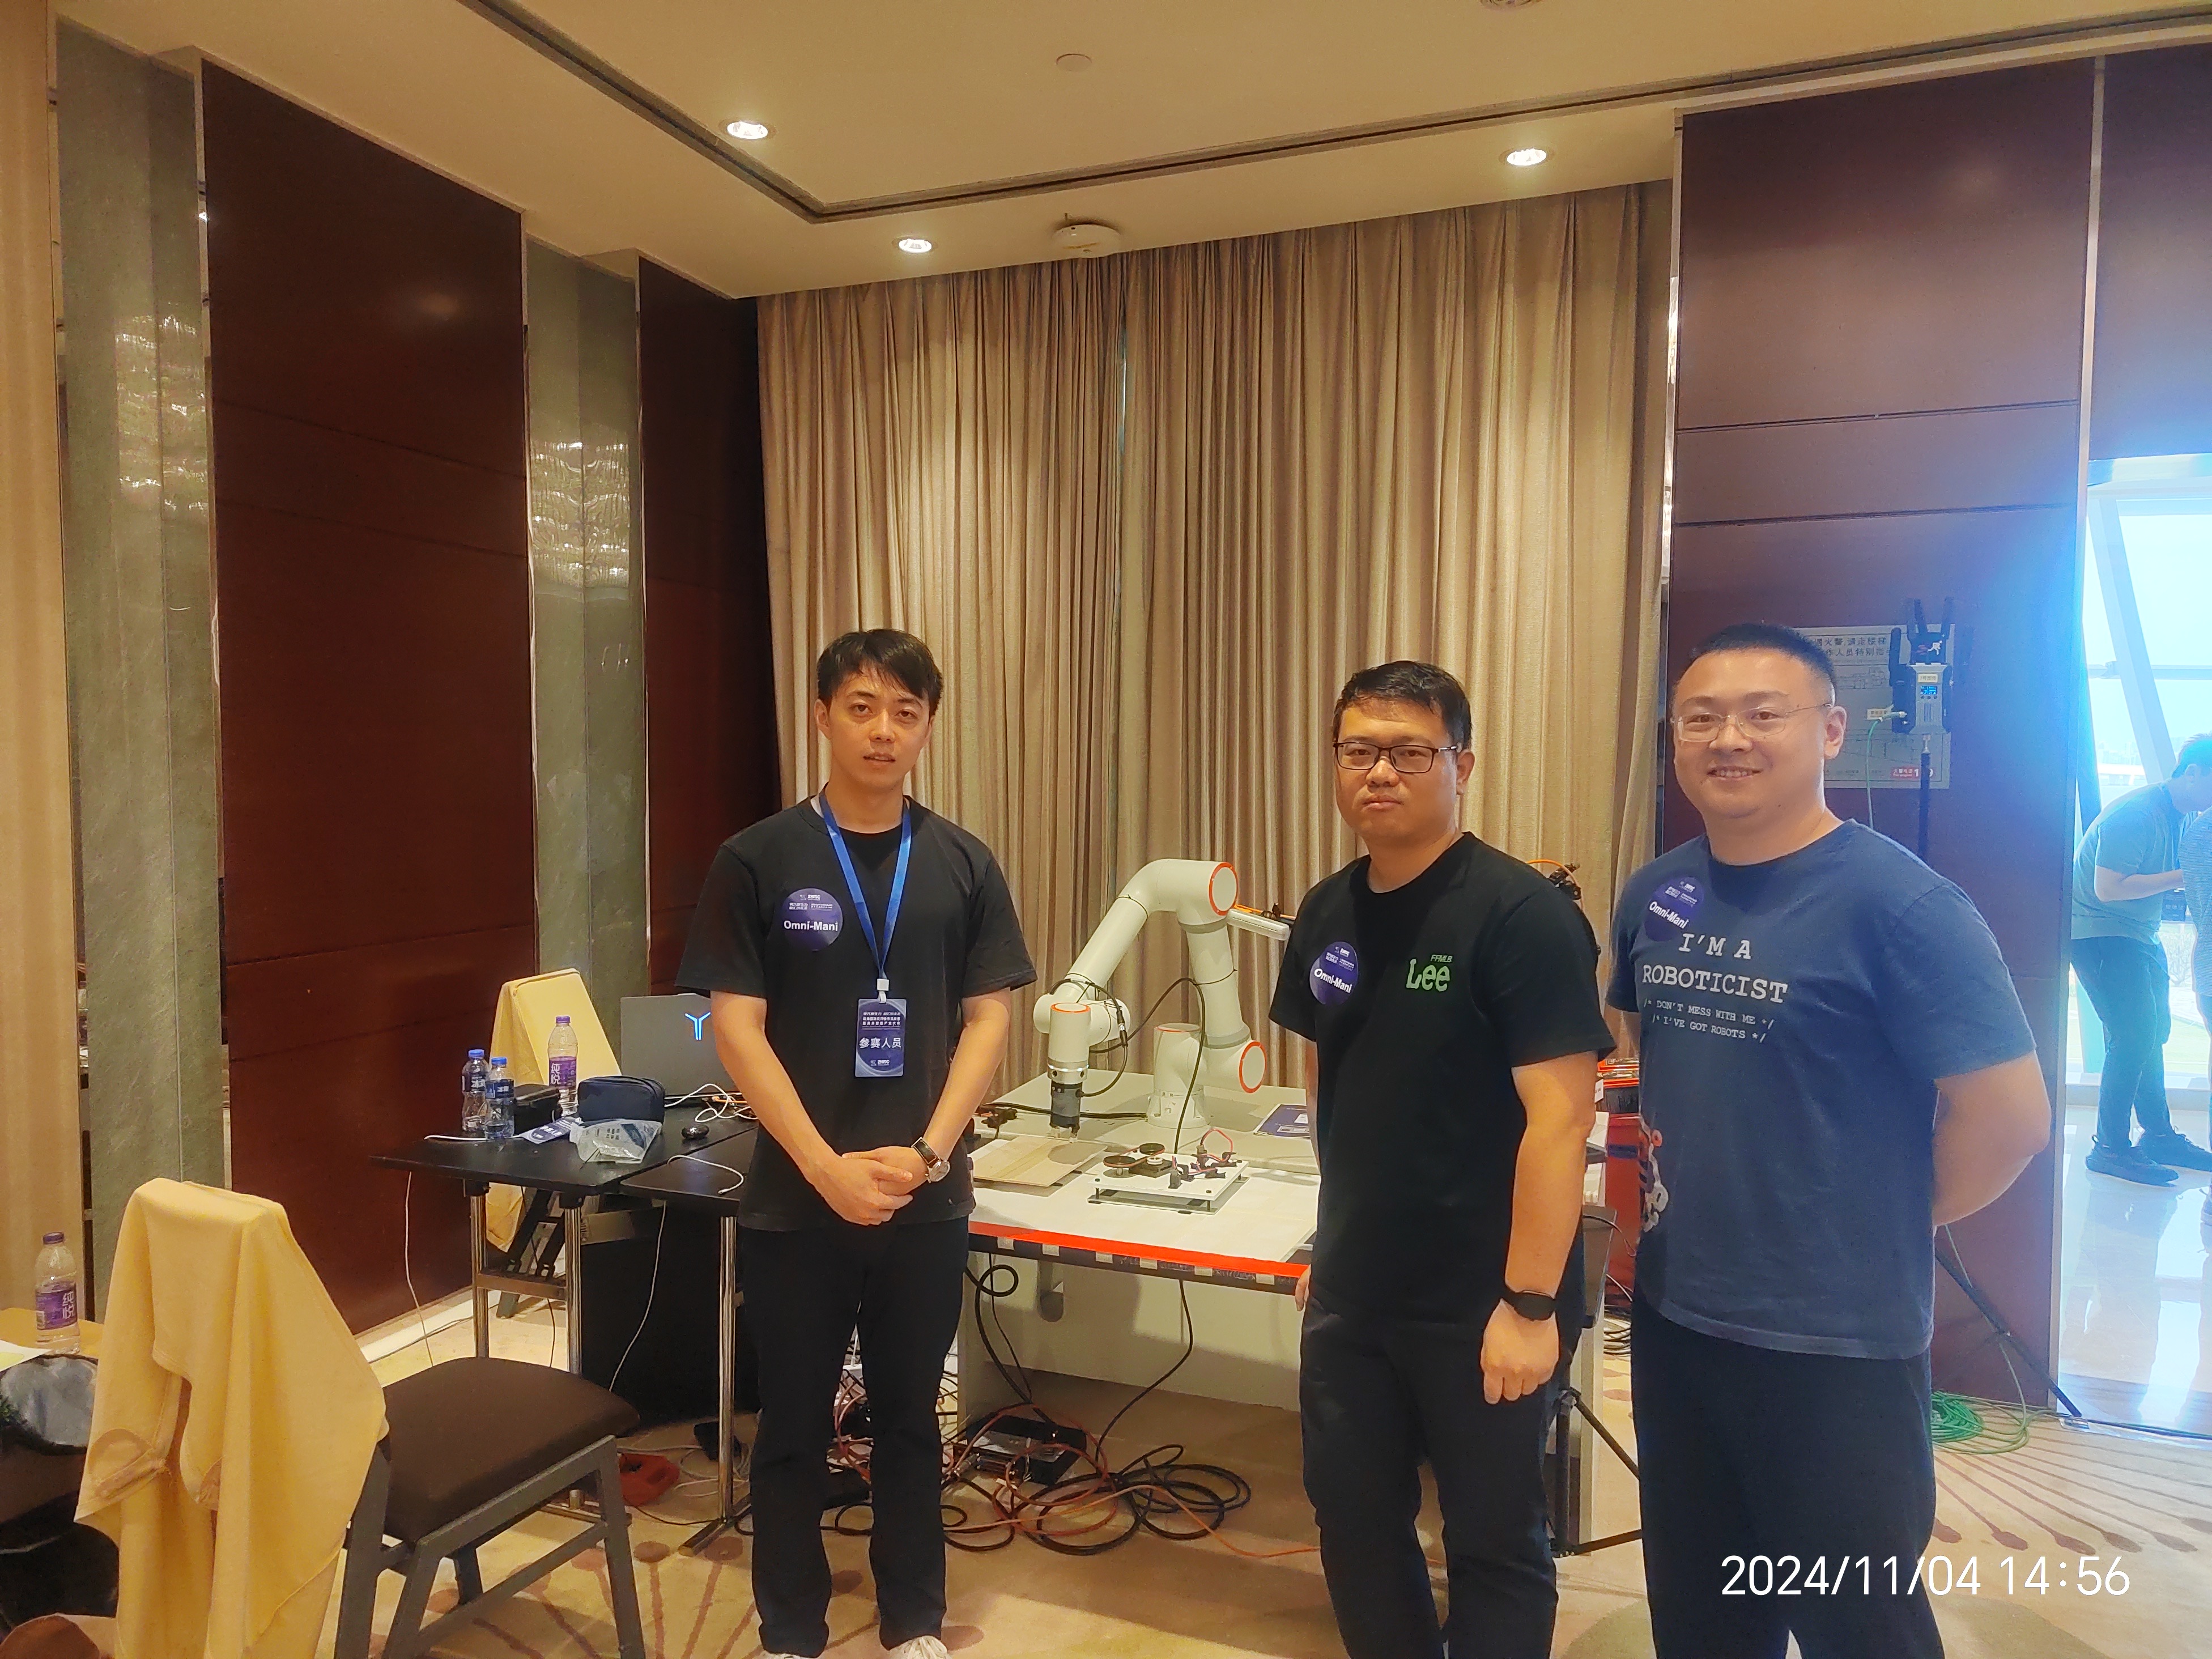
珠海国际灵巧操作挑战赛-赛道三(机器人杂乱线缆整理插拔任务)-第一名, 2024
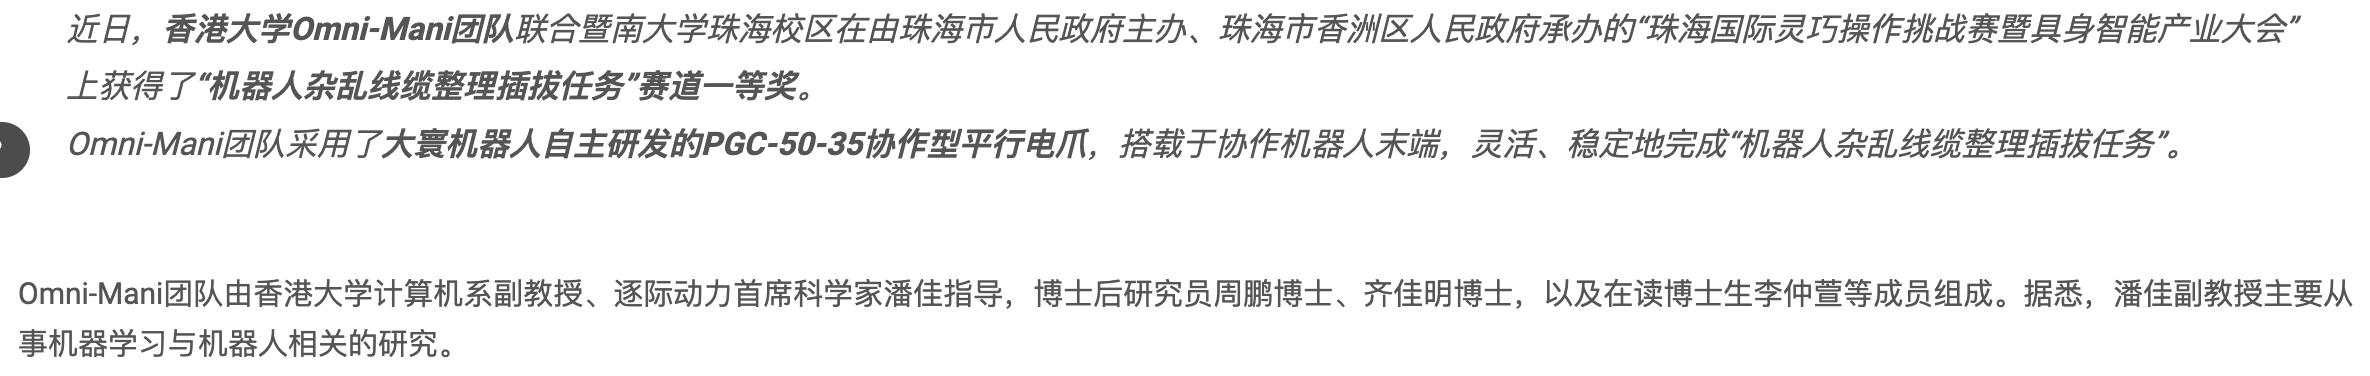
Championship Award (1st Place), Zhuhai International Dexterous Manipulation Challenge - Track 3 (Robot Messy Cable Management and Plug-in Task) News Report / View Gallery Led by Prof. Jia Pan at HKU, our Omni-Mani team achieved first place in the deformable object manipulation challenge, demonstrating advanced robotics capabilities in cable management tasks. |


|
|
|
一种IMU和无线通信结合的户型图生成装置与方法 (CN116939529A)
Positioning method and related device (WO2023185902A1) Link |
|
This website design is inspired by Jon Barron |